3 Fourier Series and Fourier Transform
Learning Objectives
After reading this chapter, you should be able to:
- Express a periodic function as a Fourier series and relate this process to projecting a vector onto an orthogonal basis
- Use the orthogonality of the trigonometric (and complex exponential) basis functions to derive the Fourier series coefficients
- Convert between the real (trigonometric) and complex (exponential) forms of the Fourier series
- Derive the Fourier transform and its inverse as the limiting case of the Fourier series as the period tends to infinity
- Apply the linearity, differentiation and convolution properties of the Fourier transform
- Use Fourier transform pairs to obtain the frequency response (RAO) and the impulse response function of a single degree of freedom system
- Explain the notion of causality and its role in defining a physically realizable impulse response function
- Compute the response of a single degree of freedom system to an arbitrary (non-sinusoidal) forcing using the convolution integral
3.1 Motivation
In the previous chapter we looked at the response of a single degree of freedom system excited by a sinusoidal force. We know that eventually when we want to compute the motions of a ship or offshore structure in the ocean, the excitation due to waves and wind will not be sinusoidal but will be random. Thus, there is a need to understand how we can scale from the simple case of sinusoidal forcing to a random forcing. In this chapter we will move towards this by learning about Fourier series and Fourier transforms.
3.2 Fourier series
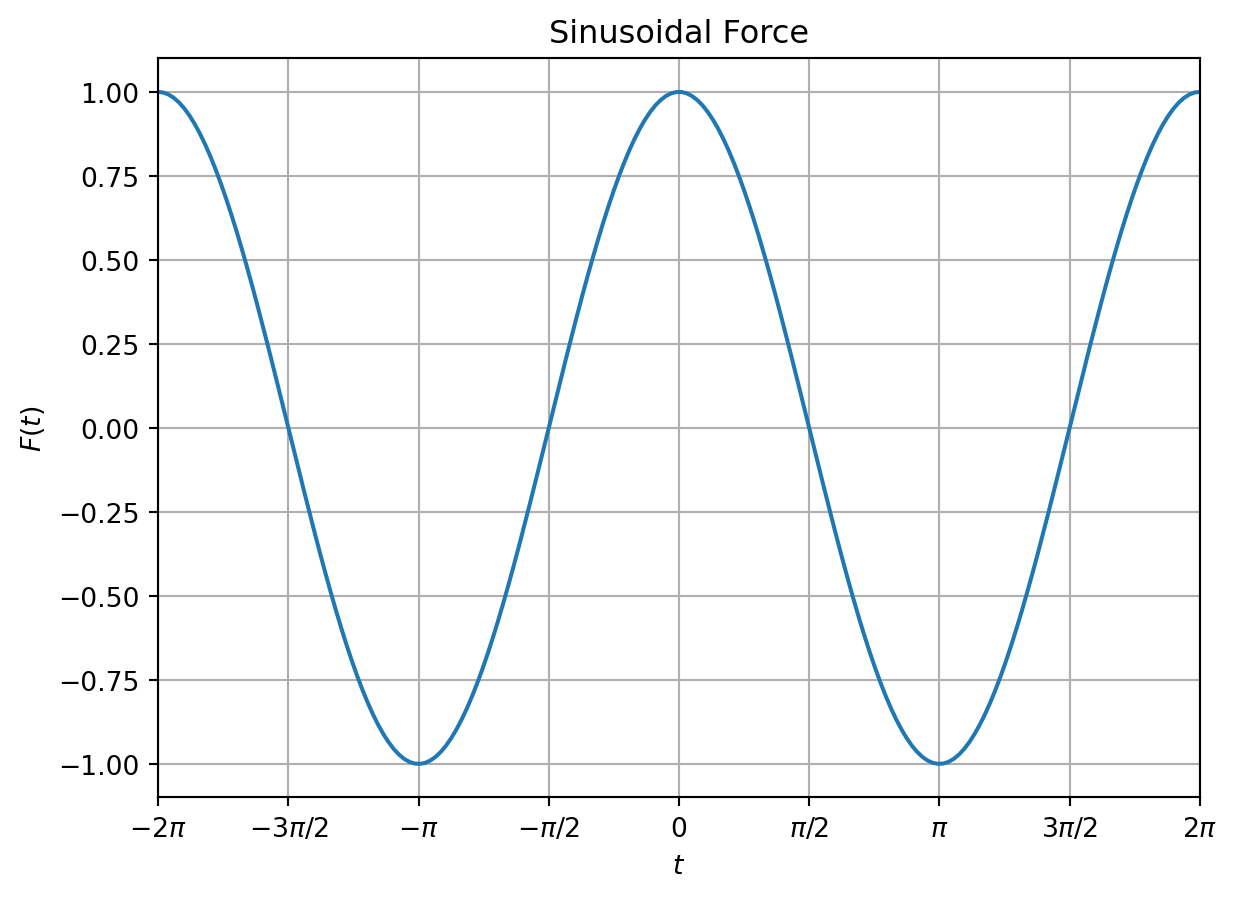
In the previous chapter we looked at a sinusoidal forcing of the type \(F(t) = F_0 cos(\omega t)\). This forcing as seen in Figure 3.1 will repeat itself over time and has a period of \(T = 2\pi/\omega\).
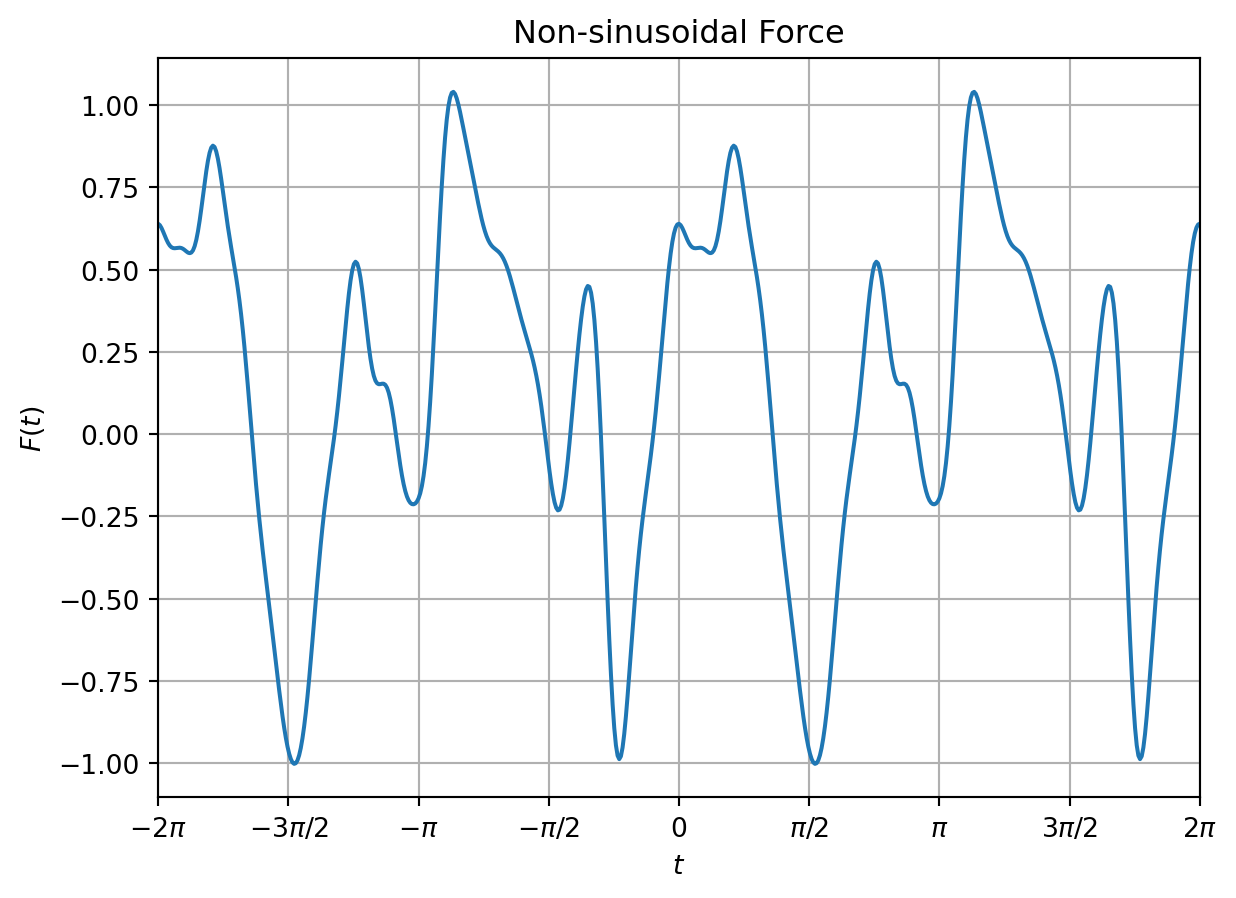
Now let’s consider a funtion \(F(t)\) that is continuous and periodic over the time interval \([-\frac{T}{2}, \frac{T}{2}]\). An example is shown in Figure 3.2, where the function is periodic with a period \(T=2\pi\) but is not sinusoidal.
Fourier showed that as long as the function \(F(t)\) is smooth, continuous and periodic, it can be expressed as a trignometric series:
\[\begin{align} F(t) = \frac{a_0}{2} + \sum_{k=1}^{\infty} a_k \cos(k\omega_0 t) + b_k \sin(k\omega_0 t) \label{eq-real-fourier-series} \end{align}\]
where \(\omega_0 = 2\pi/T\) is known as the fundametal frequency of the Fourier series and \(T\) is the fundametal period of the function.
We will now compare this exercise of expressing a function as a Fourier series with the more familiar concept of projecting a vector in 3D vector space along its basis vectors. We know that in 3D space, a vector \(\vec{\boldsymbol{r}}\) is expressed in terms of its projection along the basis vectors as:
\[\begin{align} \vec{\boldsymbol{r}} = a \boldsymbol{\hat{i}} + b \boldsymbol{\hat{j}} + c \boldsymbol{\hat{k}} \end{align}\]
where \(\boldsymbol{\hat{i}}\), \(\boldsymbol{\hat{j}}\) and \(\boldsymbol{\hat{k}}\) are unit vectors along the cardinal directions (\(x\), \(y\) and \(z\) directions) and the values \(a\), \(b\) and \(c\) are the projection of the vector \(\vec{\boldsymbol{r}}\) along \(\boldsymbol{\hat{i}}\), \(\boldsymbol{\hat{j}}\) and \(\boldsymbol{\hat{k}}\).
We can think of a Fourier series as projecting the funtion \(F(t)\) along the basis functions \(\cos(k\omega_0 t)\) and \(\sin(k\omega_0 t)\) for \(k=1,2,...,\infty\). The only difference here is that we are projecting functions into function space and unlike the 3D vector space that has only 3 basis vectors, here we have infinte number of basis functions. The coefficients \(a_k\) and \(b_k\) denote the projection of the function \(F(t)\) along \(\cos(k\omega_0 t)\) and \(\sin(k\omega_0 t)\) respectively.
In the vector space, the cardinal vectors \(\boldsymbol{\hat{i}}\), \(\boldsymbol{\hat{j}}\) and \(\boldsymbol{\hat{k}}\) are orthogonal to each other. This means that when we project one cardinal vector along another, the projection is zero. This idea of projecting one vector along another is denoted by the dot product (or scalar product) operation and the orthogonality is expressed mathematically as:
\[\begin{align} \boldsymbol{\hat{i}}.\boldsymbol{\hat{j}} = \boldsymbol{\hat{i}}.\boldsymbol{\hat{k}} = \boldsymbol{\hat{j}}.\boldsymbol{\hat{k}} = 0 \label{eq-vec-orthogonality} \end{align}\]
The idea of dot product also transfers over to the function spaces. The dot product between two functions \(f(t)\) and \(g(t)\) with domain \([-\frac{T}{2}, \frac{T}{2}]\) is defined as:
\[\begin{align} <f,g> = \int_{-T/2}^{T/2} f(t) g^{*}(t) dt \end{align}\]
where \(g^{*}(t)\) is the complex conjugate of \(g(t)\). If the functions are real valued, then the dot product reduces to:
\[\begin{align} <f,g> = \int_{-T/2}^{T/2} f(t) g(t) dt \end{align}\]
Just as we had the orthogonality of basis vectors as shown in \(\eqref{eq-vec-orthogonality}\), the basis functions \(\cos(k\omega_0 t)\) and \(\sin(k\omega_0 t)\) for \(k=1,2,...,\infty\) are also orthogonal to each other.
\[\begin{align} <\cos(k\omega_0 t), \cos(m\omega_0 t)> &= \int_{-T/2}^{T/2} \cos(k\omega_0 t) \cos(m\omega_0 t) dt \nonumber \\ &= \int_{-T/2}^{T/2} \frac{1}{2}\left\{\cos((k+m)\omega_0 t) + \cos((k-m)\omega_0 t)\right\} dt \nonumber \\ &= \begin{cases} 0 & \text{for } k \neq m \\ \frac{T}{2} & \text{for } k = m \end{cases} \end{align}\]
\[\begin{align} <\sin(k\omega_0 t), \sin(m\omega_0 t)> &= \int_{-T/2}^{T/2} \sin(k\omega_0 t) \sin(m\omega_0 t) dt \nonumber \\ &= \int_{-T/2}^{T/2} \frac{1}{2}\left\{\cos((k-m)\omega_0 t) - \cos((k+m)\omega_0 t)\right\} dt \nonumber \\ &= \begin{cases} 0 & \text{for } k \neq m \\ \frac{T}{2} & \text{for } k = m \end{cases} \end{align}\]
\[\begin{align} <\cos(k\omega_0 t), \sin(m\omega_0 t)> &= \int_{-T/2}^{T/2} \cos(k\omega_0 t) \sin(m\omega_0 t) dt \nonumber \\ &= \int_{-T/2}^{T/2} \frac{1}{2}\left\{\sin((k+m)\omega_0 t) - \sin((k-m)\omega_0 t)\right\} dt \nonumber \\ &= 0 \end{align}\]
Using the orthogonality, the coefficients of the Fourier series can be found as:
\[\begin{align} a_0 &= \frac{2}{T} <F, \cos(0 \times \omega_0 t)> = \frac{2}{T} <F, 1> \\ a_k &= \frac{2}{T} <F, \cos(k \omega_0 t)> \\ b_k &= \frac{2}{T} <F, \sin(k \omega_0 t)> \end{align}\]
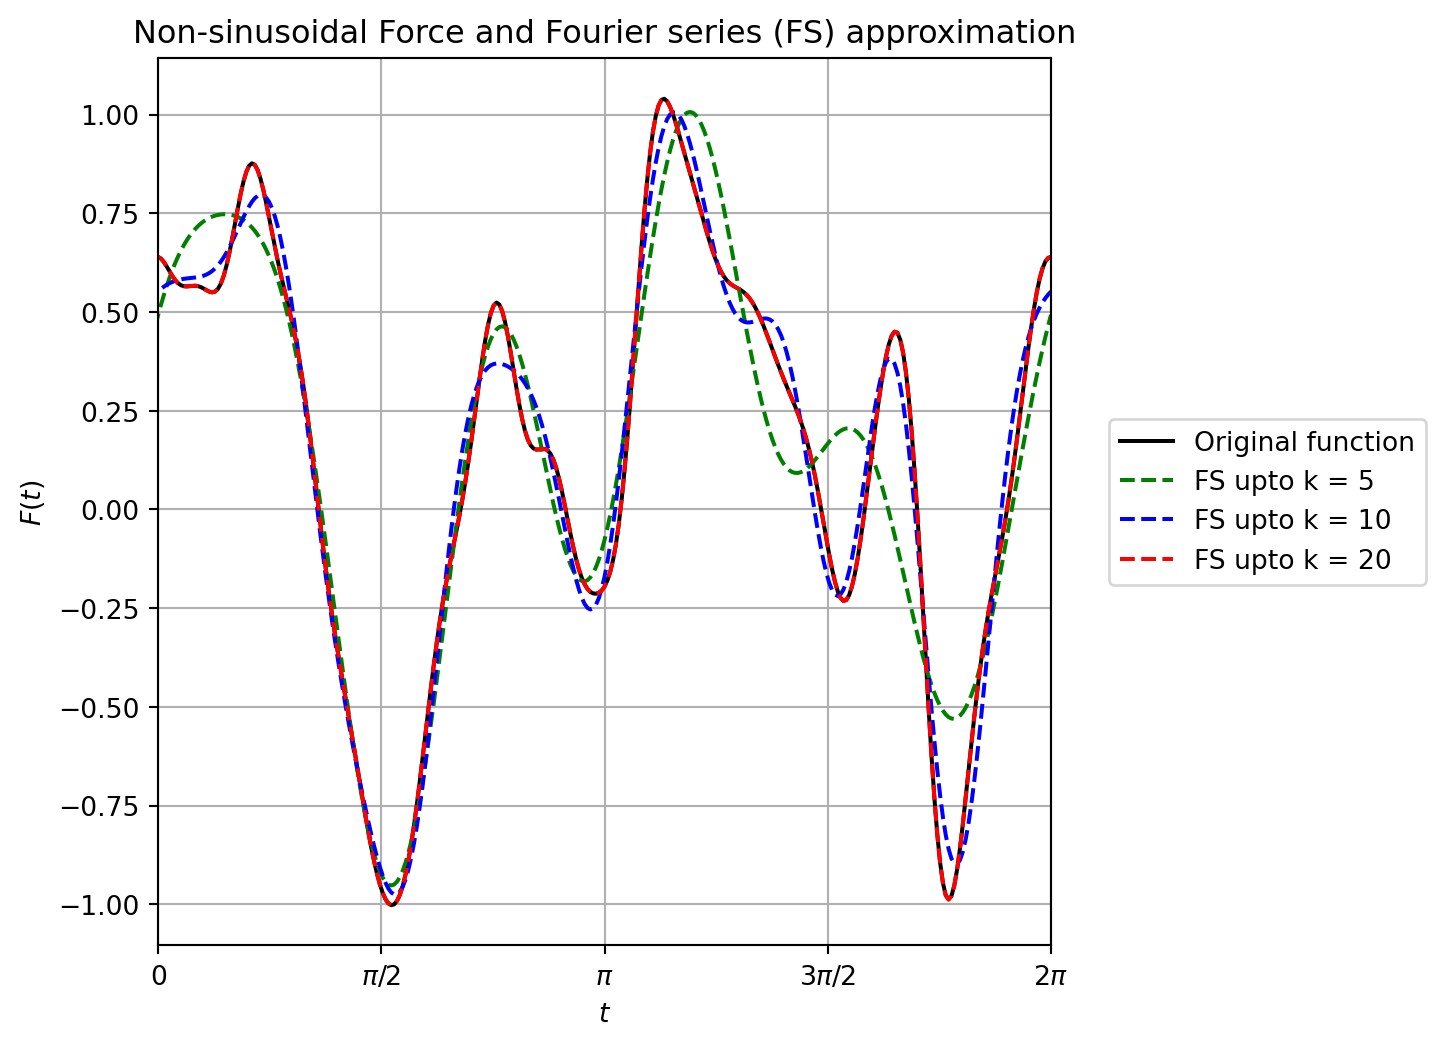
Figure 3.3 shows the Fourier series approximation of the non-sinusoidal function shown in Figure 3.2 as we progressively increase the number of terms considered for summation. It can be seen that with 10 terms the match is fairly good.
3.3 Complex Fourier series
For a real valued function \(F(t)\) defiend over \([-\frac{T}{2}, \frac{T}{2}]\), the Fourier series is given by \(\eqref{eq-real-fourier-series}\). This can further be expressed in terms of complex basis functions as:
\[\begin{align} F(t) &= \frac{a_0}{2} + \sum_{k=1}^{\infty} a_k \cos(k\omega_0 t) + b_k \sin(k\omega_0 t) \nonumber \\ &= \frac{a_0}{2} + \sum_{k=1}^{\infty} \frac{1}{2} \left[(a_k - ib_k)e^{ik\omega_0 t} + (a_k + ib_k)e^{-ik\omega_0 t} \right] \nonumber \\ &= \sum_{k=-\infty}^{\infty} c_k e^{ik\omega_0 t} \end{align}\]
where:
\[\begin{align} c_k = \begin{cases} \frac{1}{2} a_0 & k = 0 \\ \frac{1}{2} (a_k - ib_k) & k > 0 \\ \frac{1}{2} (a_k + ib_k) & k < 0 \end{cases} \end{align}\]
The same principle of orthogonality also holds for the complex basis functions too as shown below:
\[\begin{align} <e^{ik\omega_0 t}, e^{im\omega_0 t}> &= \int_{-T/2}^{T/2} e^{ik\omega_0 t} e^{-im\omega_0 t} dt \nonumber \\ &= \begin{cases} 0 & k \neq m \\ T & k = m \end{cases} \end{align}\]
Using the orthogonality, the coefficients of the Fourier series can be found as:
\[\begin{align} c_k = \frac{1}{T}<F, e^{ik\omega_0 t}> \end{align}\]
It is interesting to note that for a real function \(F(t)\), the complex Fourier coefficients have a symmetry as shown below:
\[\begin{align} c_{-k} = c_k^{*} \end{align}\]
where \((.)^{*}\) is the complex conjugate operator.
3.4 Fourier transform
The Fourier series we have discussed so far for functions periodic over a finite domain \([-\frac{T}{2}, \frac{T}{2}]\). Note that the consecutive term frequencies are discretely separated by the fundamental frequency \(\omega_0\). The Fourier series can be written as:
\[\begin{align} F(t) &= \sum_{k=-\infty}^{\infty} c_k e^{ik\omega_0 t} \nonumber \\ &= \sum_{k=-\infty}^{\infty} \frac{1}{T}<F, e^{ik\omega_0 t}> e^{ik\omega_0 t} \nonumber \\ &= \sum_{k=-\infty}^{\infty} \frac{\omega_0}{2\pi} \int_{-T/2}^{T/2} F(\xi)e^{-ik\omega_0 \xi} d\xi ~e^{ik\omega_0 t} \end{align}\]
We now extend this idea of Fourier series to functions defined over the domain \((-\infty, \infty)\) by taking the limit \(T \rightarrow \infty\). Note that this means that the fundamental frequency \(\omega_0 \rightarrow d\omega\) and the sum over a discrete set of frequencies (each consecutive one separated by \(\omega_0\)) can be considered as an integral over continuous set of frequencies \(\omega\) in the limit.
\[\begin{align} F(t) &= \lim_{\substack{T\rightarrow \infty \\ \omega_0 \rightarrow d\omega}} \sum_{k=-\infty}^{\infty} \frac{\omega_0}{2\pi} \int_{-T/2}^{T/2} F(\xi)e^{-ik\omega_0 \xi} d\xi ~e^{ik\omega_0 t} \nonumber \\ &= \frac{1}{2\pi} \int_{-\infty}^{\infty} \int_{-\infty}^{\infty} F(\xi)e^{-i\omega \xi} d\xi ~e^{i\omega t} d\omega \end{align}\]
The inner integral is the Fourier transform of the continuous function \(F(t)\) defined over the domain \((-\infty, \infty)\).
\[\begin{align} \hat{F}(\omega) = \mathcal{F}(F(t)) = \int_{-\infty}^{\infty} F(t)e^{-i\omega t} dt \end{align}\]
Similarly the outer integral is the inverse Fourier transform of the continuous function \(\hat{F}(\omega)\) defined over the domain \((-\infty, \infty)\).
\[\begin{align} F(t) = \mathcal{F}^{-1}(\hat{F}(\omega)) = \frac{1}{2\pi} \int_{-\infty}^{\infty} \hat{F}(\omega) e^{i\omega t} d\omega \end{align}\]
The two integrals are known as Fourier transform pair. Both integrals converge as long as \(\int_{-\infty}^{\infty} |F(t)| dt < \infty\) and \(\int_{-\infty}^{\infty} |\hat{F}(\omega)| d\omega < \infty\). The Fourier transform and inverse Fourier transform are both linear operators and accommodate the principle of superposition.
\[\begin{align} \mathcal{F}(af(t) + bg(t)) &= a \mathcal{F}(f) + b \mathcal{F}(g) = a \hat{f}(\omega) + b \hat{f}(\omega) \\ \mathcal{F}^{-1}(a\hat{f}(\omega) + b\hat{g}(\omega)) &= a \mathcal{F}^{-1}(\hat{f}) + b \mathcal{F}^{-1}(\hat{g}) = a f(t) + b f(t) \end{align}\]
The Fourier transform gives us another way to compute the derivative of a function.
\[\begin{align} \frac{dF}{dt} &= \frac{d}{dt} \left(\frac{1}{2\pi}\int_{-\infty}^{\infty} \hat{F}(\omega)e^{i\omega t} d\omega\right) \nonumber\\ &= \frac{1}{2\pi}\int_{-\infty}^{\infty} \hat{F}(\omega)\frac{d}{dt}\left(e^{i\omega t}\right) d\omega \nonumber\\ &= \frac{1}{2\pi}\int_{-\infty}^{\infty} \hat{F}(\omega) i\omega e^{i\omega t} d\omega \nonumber\\ &= \mathcal{F}^{-1}(i\omega \hat{F}(\omega)) \end{align}\]
Thus the Fourier transform of a derivative is equivalent to mulitplying the Fourier transform of the function with \(i\omega\). This usefult property allows converting partial differntial equations into ordinary differential equations. We will use this property later when we discuss hydrodynamics of floating structures.
Another useful property of the Fourier transform is that it converts the convolution operation between two functions in the time domain into a product operation in the frequency domain. The convolution operation between two functions \(f(t)\) and \(g(t)\) is defined as:
\[\begin{align} f * g (t) = \int_{-\infty}^{\infty} f(\tau)g(t - \tau) d\tau \end{align}\]
The Fourier transform of the convolution operation yields:
\[\begin{align} \mathcal{F}(f * g) &= \int_{-\infty}^{\infty} \int_{-\infty}^{\infty} f(\tau)g(t - \tau) d\tau e^{-i\omega t} dt \nonumber \\ &= \int_{-\infty}^{\infty} \int_{-\infty}^{\infty} f(\tau)g(t - \tau) e^{-i\omega (t-\tau)} e^{-i\omega \tau}d\tau dt \nonumber \\ &= \int_{-\infty}^{\infty} \int_{-\infty}^{\infty} f(\tau)g(t - \tau) e^{-i\omega (t-\tau)} dt e^{-i\omega \tau}d\tau \nonumber \\ &= \int_{-\infty}^{\infty} f(\tau) \int_{-\infty}^{\infty} g(\xi) e^{-i\omega \xi} d\xi e^{-i\omega \tau}d\tau \nonumber \\ &= \int_{-\infty}^{\infty} f(\tau) \hat{g}(\omega) e^{-i\omega \tau}d\tau \nonumber \\ &= \int_{-\infty}^{\infty} f(\tau) e^{-i\omega \tau}d\tau \hat{g}(\omega)\nonumber \\ &= \hat{f}(\omega) \hat{g}(\omega) \end{align}\]
Table 3.1 lists some commonly used Fourier transform pairs. Here \(u(t)\) is the unit step function (\(u(t) = 1\) for \(t \geq 0\) and \(0\) otherwise), \(\text{sgn}(t)\) is the signum function (\(\text{sgn}(t) = 1\) for \(t > 0\), \(-1\) for \(t < 0\)) and \(\delta(t)\) is the Dirac delta function.
| Sl. No. | \(f(t)\) | \(\hat{f}(\omega)\) |
|---|---|---|
| 1 | \(\delta(t)\) | \(1\) |
| 2 | \(1\) | \(2\pi\delta(\omega)\) |
| 3 | \(\delta(t - t_0)\) | \(e^{-i\omega t_0}\) |
| 4 | \(e^{i\omega_0 t}\) | \(2\pi\delta(\omega - \omega_0)\) |
| 5 | \(\cos(\omega_0 t)\) | \(\pi\left[\delta(\omega - \omega_0) + \delta(\omega + \omega_0)\right]\) |
| 6 | \(\sin(\omega_0 t)\) | \(\dfrac{\pi}{i}\left[\delta(\omega - \omega_0) - \delta(\omega + \omega_0)\right]\) |
| 7 | \(u(t)\) | \(\pi\delta(\omega) + \dfrac{1}{i\omega}\) |
| 8 | \(\text{sgn}(t)\) | \(\dfrac{2}{i\omega}\) |
| 9 | \(e^{-\alpha t}u(t)\), \(\alpha > 0\) | \(\dfrac{1}{\alpha + i\omega}\) |
| 10 | \(t\,e^{-\alpha t}u(t)\), \(\alpha > 0\) | \(\dfrac{1}{(\alpha + i\omega)^2}\) |
| 11 | \(e^{-\alpha \lvert t \rvert}\), \(\alpha > 0\) | \(\dfrac{2\alpha}{\alpha^2 + \omega^2}\) |
| 12 | \(u(t)\cos(\omega_0 t)\) | \(\dfrac{\pi}{2}\left[\delta(\omega - \omega_0) + \delta(\omega + \omega_0)\right] + \dfrac{i\omega}{\omega_0^2 - \omega^2}\) |
| 13 | \(u(t)\sin(\omega_0 t)\) | \(\dfrac{\pi}{2i}\left[\delta(\omega - \omega_0) - \delta(\omega + \omega_0)\right] + \dfrac{\omega_0}{\omega_0^2 - \omega^2}\) |
| 14 | \(u(t)e^{-\alpha t}\cos(\omega_0 t)\), \(\alpha > 0\) | \(\dfrac{\alpha + i\omega}{(\alpha + i\omega)^2 + \omega_0^2}\) |
| 15 | \(u(t)e^{-\alpha t}\sin(\omega_0 t)\), \(\alpha > 0\) | \(\dfrac{\omega_0}{(\alpha + i\omega)^2 + \omega_0^2}\) |
| 16 | \(f(t) = 1\) for \(\lvert t \rvert < \tau/2\), \(0\) otherwise | \(\dfrac{2\sin(\omega\tau/2)}{\omega}\) |
| 17 | \(f(t) = \dfrac{\sin(Wt)}{\pi t}\) | \(\hat{f}(\omega) = 1\) for \(\lvert \omega \rvert < W\), \(0\) otherwise |
| 18 | \(f(t) = \tau - \lvert t \rvert\) for \(\lvert t \rvert < \tau\), \(0\) otherwise | \(\dfrac{4\sin^2(\omega\tau/2)}{\omega^2}\) |
| 19 | \(e^{-\alpha t^2}\), \(\alpha > 0\) | \(\sqrt{\dfrac{\pi}{\alpha}}\, e^{-\omega^2/4\alpha}\) |
| 20 | \(\displaystyle\sum_{n=-\infty}^{\infty} c_n e^{in\omega_0 t}\) | \(\displaystyle 2\pi\sum_{n=-\infty}^{\infty} c_n \delta(\omega - n\omega_0)\) |
The last entry shows that the Fourier transform of a periodic signal, expressed as a complex Fourier series (as in the previous section), is a train of impulses in the frequency domain located at the harmonics \(n\omega_0\) and weighted by the corresponding Fourier series coefficients \(c_n\).
3.5 Dirac delta function
Consider the first two rows of Table 3.1. It show that the Fourier transform of a constant signal in the time domain is a dirac delta function in the frequency domain and viceversa. This might feel unintuitive at first and needs a closer look to appreciate. Let’s consider a time domain signal that is constant in the range \([-\frac{T}{2},\frac{T}{2}]\) and zero outside. This function is defined mathematically as:
\[\begin{align} f(t) = \begin{cases} 1 & -\frac{T}{2} \leq t \leq \frac{T}{2} \\ 0 & \text{otherwise} \end{cases} \end{align}\]
The Fourier transform of this function is given by:
\[\begin{align} \hat{f}(\omega) &= \int_{-\infty}^{\infty} f(t) e^{-i \omega t} dt \nonumber \\ &= \int_{-T/2}^{T/2} e^{-i \omega t} dt \nonumber \\ &= \frac{e^{-i \omega T/2} - e^{i \omega T/2}}{-i \omega} = T\frac{\sin\left(\frac{\omega T}{2}\right)}{\frac{\omega T}{2}} \nonumber \\ &= T \text{sinc}\left(\frac{\omega T}{2}\right) \label{eq-dirac-fourier} \end{align}\]
Note that the area under the curve is independent of \(T\) as shown below.
\[\begin{align} \int_{-\infty}^{\infty} T \frac{\sin\left(\frac{\omega T}{2}\right)}{\frac{\omega T}{2}} d\omega = 2 \pi \end{align}\]
The animation in Figure 3.4 shows how the Fourier transform \(\hat{f}(\omega)\) shown in \(\eqref{eq-dirac-fourier}\) in the limit \(T \rightarrow 0\) approaches \(2\pi\delta(\omega)\).
3.6 Application to single degree of freedom system
Let’s revisit our differential equation in the forced vibration case:
\[\begin{align} \frac{d^2x}{dt^2} + 2\zeta\omega_n\frac{dx}{dt} + \omega_n^2 x = f(t) = \frac{F(t)}{m} \end{align}\]
Taking a Fourier transform of our differential equation and using the properties of Fourier transform for the derivatives yields:
\[\begin{align} \mathcal{F}(f(t)) &= \mathcal{F} \left(\frac{d^2x}{dt^2} + 2\zeta\omega_n\frac{dx}{dt} + \omega_n^2 x\right) \nonumber \\ \hat{f}(\omega) &= \left((i\omega)^2 + 2\zeta\omega_n (i\omega) + \omega_n^2 \right) \hat{x}(\omega) \nonumber\\ \frac{\hat{x}(\omega)}{\hat{f}(\omega) / \omega_n^2} &= \frac{1}{\left(1 - \frac{\omega^2}{\omega_n^2}\right) + i2\zeta\frac{\omega}{\omega_n}} = H(\omega) \equiv \hat{h} (\omega) \end{align}\]
the same RAO \(\hat{h} (\omega) \equiv H(\omega)\) that we saw in the previous chapter. Thus the Fourier transform of the response \(\hat{x}(\omega)\) is given by:
\[\begin{align} \hat{x}(\omega) = \frac{\hat{h}(\omega) \hat{f}(\omega)}{\omega_n^2} = \frac{\hat{h}(\omega) \hat{F}(\omega)}{k} \end{align}\]
Now we can apply the inverse Fourier transform and use the property of the Fourier transform for the convolution integral to get:
\[\begin{align} x(t) &= \mathcal{F}^{-1}(\hat{x}(\omega)) = \mathcal{F}^{-1}\left(\frac{\hat{h}(\omega) \hat{F}(\omega)}{k}\right) \nonumber \\ &= \frac{1}{k} \int_{-\infty}^{t} F(t) h(t - \tau) d\tau \label{eq-irf-conv} \end{align}\]
where \(h(t) = \mathcal{F}^{-1}(\hat{h}(\omega))\) is known as the impulse response function (IRF) for the system and is the inverse Fourier transform of the RAO. Note the integral upper limit is upto \(t\) and not \(\infty\). This is so to make sure causality is maintained. In physical systems, a force (cause) at a specific time can affect the response (effect) only at that time and in the future. We cannot have a force (cause) in the future affect the response (effect) in the past. Such systems where this cause and effect relationship is maintained are called causal systems. If the upper limit of the integral in \(\eqref{eq-irf-conv}\) is allowed to be \(\infty\), then a force in the future \(F(t')\) with \(t' > t\) can affect the response \(x(t)\) at time \(t\). This breaks causality and is unphysical.
Using the Fourier transform pairs shown in Table 3.1, we can compute the closed form expression for the impulse response function as:
\[\begin{align} h(t) &= \mathcal{F}^{-1}\left(\frac{1}{\left(1 - \frac{\omega^2}{\omega_n^2}\right) + i2\zeta\frac{\omega}{\omega_n}}\right) \nonumber \\ &= \mathcal{F}^{-1}\left(\frac{\omega_n^2}{\left(\omega_n^2 - \omega^2\right) + i2\zeta\omega_n\omega}\right) \nonumber \\ &= \mathcal{F}^{-1}\left(\frac{\omega_n^2}{\left(\zeta\omega_n + i\omega\right)^2 + \omega_n^2(1-\zeta^2)}\right) \nonumber \\ &= \mathcal{F}^{-1}\left(\frac{\omega_n^2}{\omega_n\sqrt{1 - \zeta^2}}\frac{\omega_d}{\left(\zeta\omega_n + i\omega\right)^2 + \omega_d^2}\right) \nonumber \\ &= \frac{\omega_n}{\sqrt{1 - \zeta^2}} e^{-\zeta\omega_nt}\sin(\omega_d t) \end{align}\]
The plot of the impulse response function for \(\omega_n = 3.0\) rad/s and \(\zeta=0.1\) is shown in Figure 3.5.
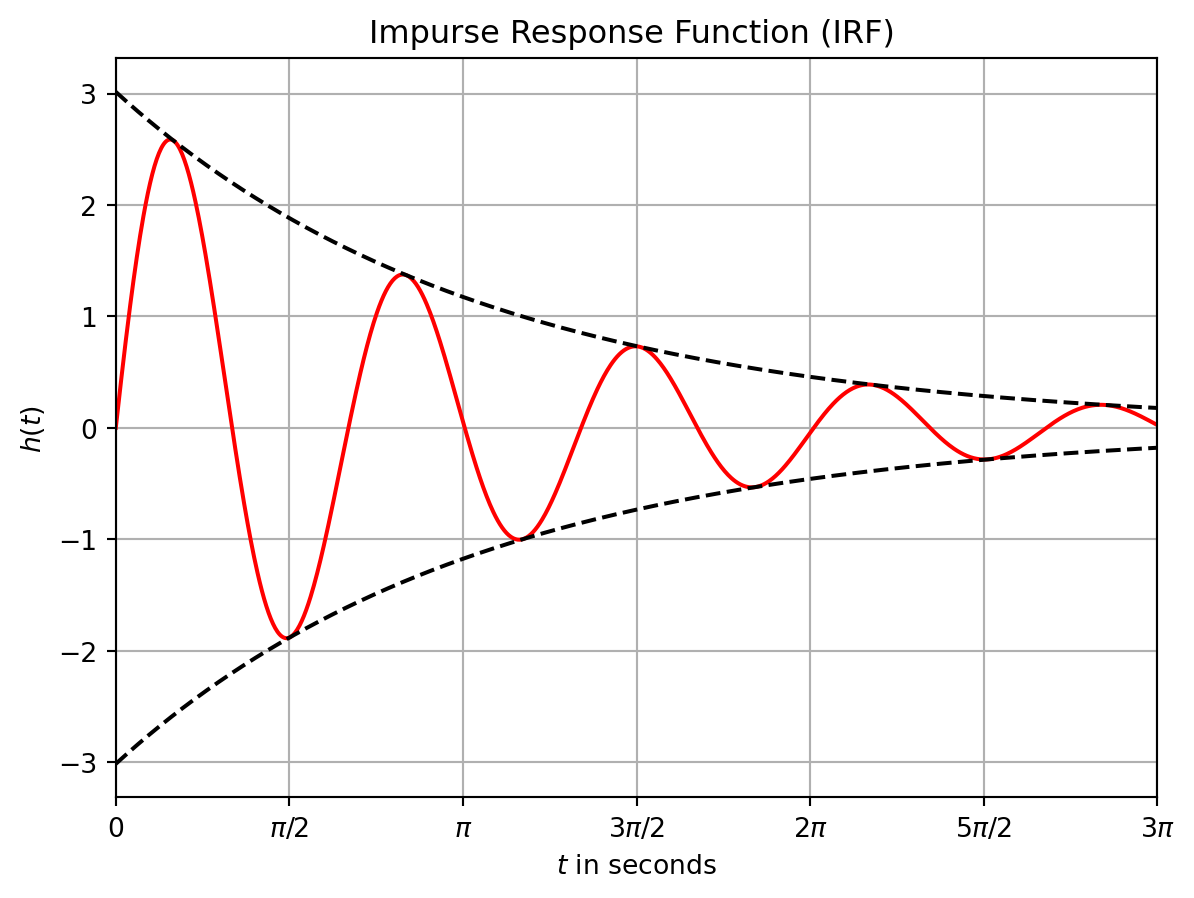
Note that this response shown in Figure 3.5 is the response of the mass when the input excitation is \(F(t) = k\delta(t)\) where \(\delta(t)\) is the Dirac delta function or the impulse function. The Dirac delta is zero everywhere except where the argument of the function is zero (in this case \(t=0\)).
Notion of sum of impluses
A general force time history can be thought of as an infinite series of impulses of strength \(F(\tau)\) at each time \(\tau\). The total response \(x(t)\) at some time \(t\) is then the sum of the individual responses to each of these impulses summed at time \(t\) due to all the impulses that came prior to time \(t\). Response of one impulse that occured at time \(\tau\) is \(F(\tau)h(t-\tau)/k\) and affects the total response for all \(t>\tau\). We need to sum across all impulses that happended at all times \(\tau < t\). This is given by the following (which turns out to be the convolution integral):
\[\begin{align} x(t) = \frac{1}{k} \int_{-\infty}^{t} F(\tau)h(t-\tau) d\tau \label{eq-convolution-irf} \end{align}\]
The animation in Figure 3.6 illustrates this superposition: each impulse at time \(\tau\) contributes a response \(F(\tau)h(t-\tau)/k\) for \(t > \tau\), and the total \(x(t)\) is the sum of all such contributions.
Notice that this a huge improvement as compared to our previous chapter. There we were restricted to only sinusoidal forcing. But now for any irregular forcing \(F(t)\) we can compute the response \(x(t)\) of our single degree of freedom system.
In general computing the convolution term shown in \(\eqref{eq-convolution-irf}\) is computationally expensive as we need to slide one signal across the other and for each sliding offset we multiply the functions and calculate the area under it. The same process in Fourier domain is a lot cheaper as it is simply a multiplication of the Fourier transfrom of the functions. In adopting the computation in the Fourier domain we are essentially separating the irregular force time history into its component regular waves (through Fourier transform), computing the response of each of these regular wave components and summing them together (inverse Fourier transform) to get the response to the irregular force.
3.7 Exercises
Unless stated otherwise use \(\rho = 1025\) kg/m\(^3\) and \(g = 9.81\) m/s\(^2\). Every problem below can be solved with the Fourier series and Fourier transform results of this chapter, the single degree of freedom results of Chapter 2 (free vibration, the RAO \(H(\omega)\), the principle of superposition) and the elementary hydrostatics you already know. Wherever a hydrodynamic force acts, its amplitude is given to you: added mass, radiation damping and wave loading are not required. The two results from linear wave theory that are quoted in Problem 4 — the deep water wavelength \(\lambda = gT^2/2\pi\) and the crest speed \(c = gT/2\pi\) — are stated there for you to use and will be derived in a later chapter.
Several problems ask you to derive a result before using it numerically; the derivation carries most of the marks. The principal dimensions are representative rather than exact and are used only to give the numbers a realistic scale.
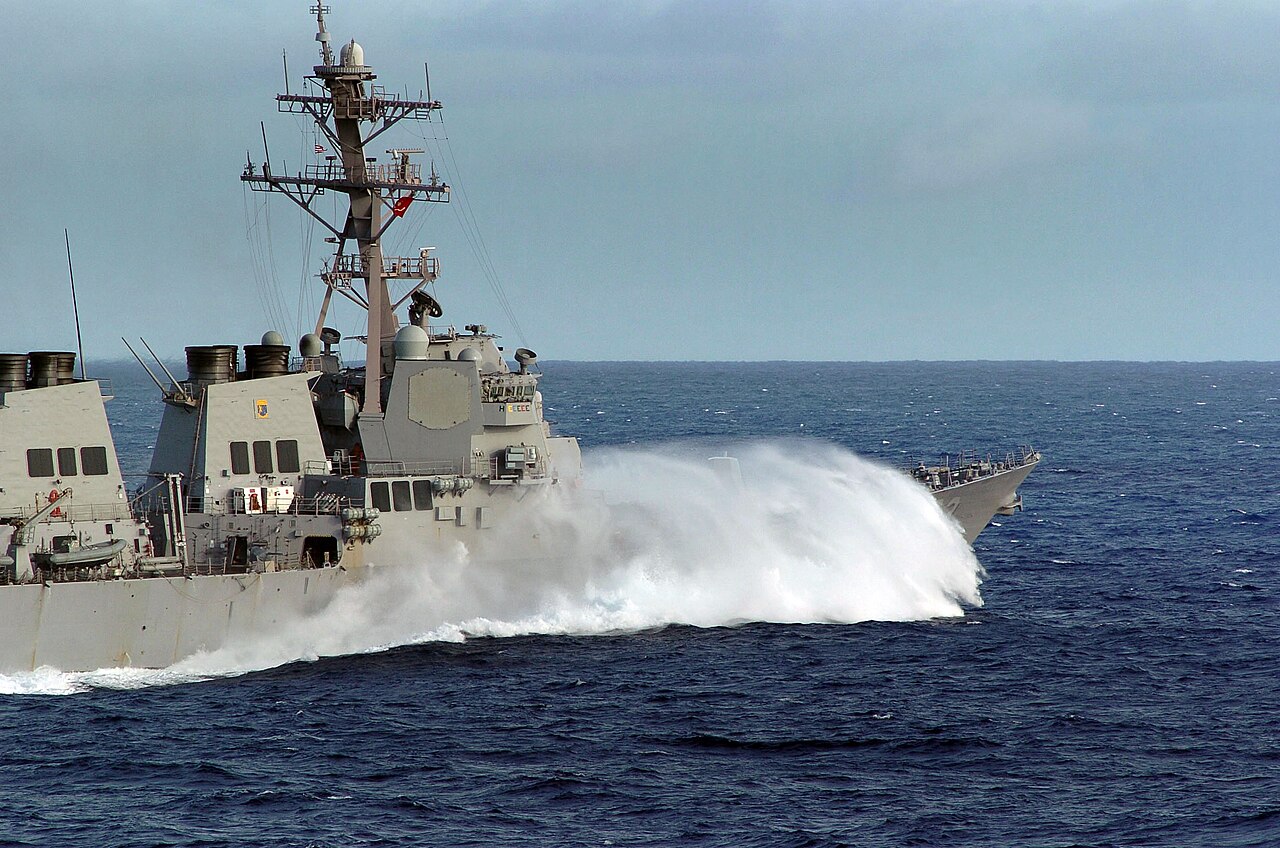
Two of the problems below concern forces that arrive as a repeating series of short blows rather than as a smooth wave. Figure 3.7 shows the physical situation. A ship driving into head seas buries her bow in a wave every few seconds; the flare of the bow strikes the water surface, and the resulting impulse is severe, brief and repeated once per wave encounter. This is the loading idealised in Problem 2, and the whole point of that problem is that a force made of short pulses carries energy at frequencies far above the wave frequency that produced it.
A thruster that cannot make up its mind. A moored construction barge is held on station in surge by a thruster that is controlled in an on–off (bang–bang) manner: it delivers a constant thrust \(F_0 = 900\) kN for exactly half of every cycle and nothing for the other half, the cycle period being \(T = 60\) s. The barge has an effective surge mass \(m = 2.4\times10^{7}\) kg, a surge natural period of \(20\) s and \(\zeta = 0.05\).
- Using the orthogonality relations of this chapter, derive the Fourier series of this on–off thrust. Show that \(a_0/2 = F_0/2\), that \(a_k = 0\) for all \(k \geq 1\), and that \(b_k = 2F_0/(k\pi)\) for odd \(k\) and zero for even \(k\). Explain, from the symmetry of \(F(t) - F_0/2\) about the time axis, why the even harmonics must be absent.
- Compute the mooring stiffness and the mean surge offset. For each of the harmonics \(k = 1, 3, 5, 7\) compute \(\omega_k\), the force amplitude, the frequency ratio \(r_k\), \(|H(\omega_k)|\), the phase and the response amplitude. Present the results as a table.
- Which harmonic dominates the motion, and why? Sum the series numerically to obtain the largest and smallest surge excursion in a cycle, and compare with the naive estimate “mean thrust divided by stiffness”.
- The operator proposes two fixes, both of which keep the mean thrust at \(450\) kN so that station-keeping is unaffected: (i) reduce the on-fraction to \(d = 1/3\) and raise the thrust to \(1350\) kN; (ii) keep \(d = 1/2\) and \(F_0 = 900\) kN but shorten the cycle period to \(45\) s. First show that for a general on-fraction \(d\) the \(k\)-th harmonic has amplitude \(2F_0\lvert\sin(\pi k d)\rvert/(\pi k)\), so that the \(k\)-th harmonic vanishes whenever \(kd\) is an integer. Then evaluate both proposals and recommend one.
- State the general lesson about eliminating a single offending harmonic.
A ship’s hull is not rigid: it rings like a beam. The lowest elastic mode of a hull girder is the two-node vertical mode sketched in Figure 3.8, in which the bow and stern move one way while amidships moves the other, and two stations along the length stay still. A slam at the bow excites this mode, and the resulting vibration — whipping — is what Problem 2 analyses. Its natural frequency is far above the wave frequencies of Figure 3.7, which is exactly why the harmonic content of a short pulse matters.
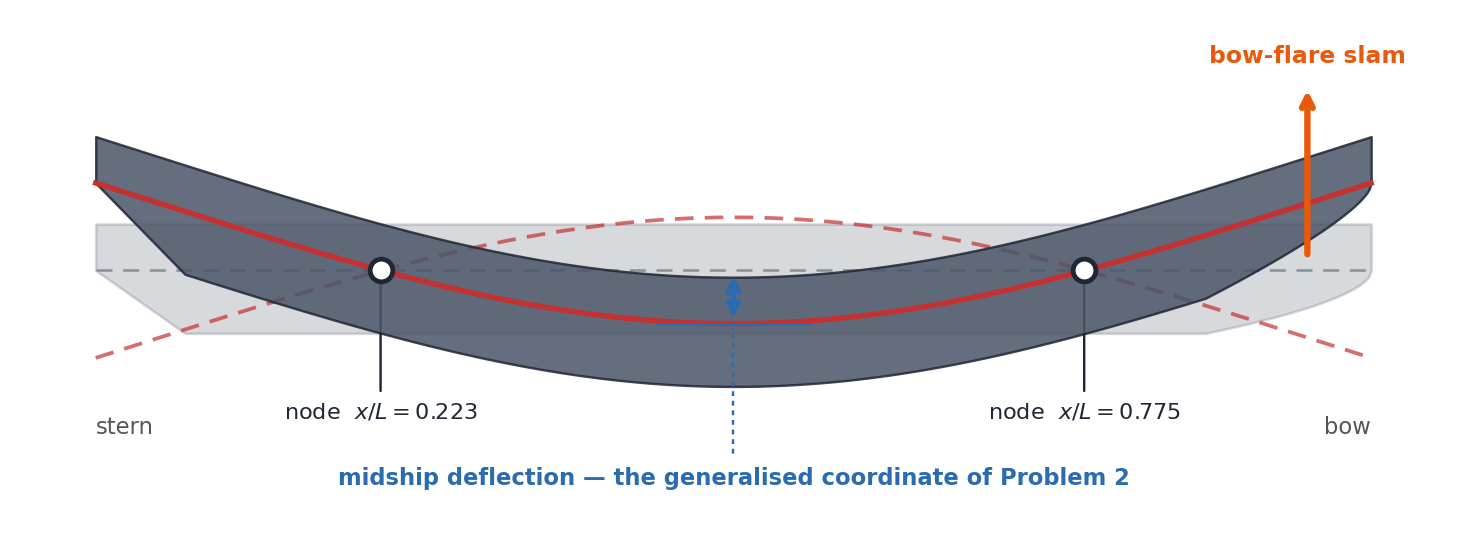
Bow slamming and the whipping of a hull girder. A ship steaming in head seas takes a bow-flare slam once every wave encounter, the encounter period being \(T_e = 7.5\) s. Each slam is idealised as a rectangular force pulse of magnitude \(F_0 = 15\) MN and duration \(\tau = 0.20\) s, repeating with period \(T_e\). The two-node vertical vibration mode of the hull girder behaves as a single degree of freedom system with generalised mass \(M = 1.2\times10^{7}\) kg, natural frequency \(1.10\) Hz and \(\zeta = 0.012\); the generalised coordinate may be read as the midship vertical deflection.
- Show that the \(k\)-th harmonic of a rectangular pulse train with on-fraction \(d = \tau/T_e\) has amplitude \(2F_0\lvert\sin(\pi k d)\rvert/(\pi k)\), and hence that for \(d \ll 1\) this is very nearly \(2F_0\tau/T_e\) — the same for every harmonic — until the envelope first vanishes at \(\omega = 2\pi/\tau\). Compute that frequency and the number of harmonics lying below it. Explain in one sentence why “a short blow is broadband”.
- Compute the modal stiffness, \(\omega_0\) and \(\omega_n/\omega_0\). Tabulate the force amplitude, \(r_k\), \(|H_k|\) and the modal response for \(k = 1, 2, 8, 9, 10\). Compare the wave-frequency (\(k=1\)) deflection with the \(k=8\) deflection and comment.
- Sum the series numerically and report the largest and smallest midship deflection, and the sum \(\sum_k |x_k|\). Why is the sum a poor estimate of the peak?
- In heavier weather the slam duration doubles to \(\tau = 0.4\) s at the same peak force. Recompute the \(k=8\) response. Then find the slam duration that would place a zero of the envelope exactly on the eighth harmonic. Is such a duration physically achievable for a slam? What does this tell you about trying to “detune” a slam?
- The master reduces speed, changing the encounter period. Compute the largest single-harmonic response for \(T_e = 6.0, 7.0, 7.5, 8.0\) and \(9.0\) s, and find the two encounter periods near \(7.5\) s that place a harmonic exactly on \(\omega_n\). What is the worst case, and what is the only reliable remedy?
How many harmonics do you actually need? Every practical calculation truncates the Fourier series. This problem establishes how to decide where to stop.
- Starting from the orthogonality relations, show that for a real periodic \(F(t)\) \[\overline{F^2} \equiv \frac{1}{T}\int_{-T/2}^{T/2} F^2(t)\,dt = \frac{a_0^2}{4} + \frac{1}{2}\sum_{k=1}^{\infty}\left(a_k^2 + b_k^2\right) = \sum_{k=-\infty}^{\infty}\lvert c_k\rvert^2\] This is Parseval’s theorem: the mean square of a signal is the sum of the mean squares of its harmonics, and no cross terms survive.
- Apply it to a zero-mean square wave of amplitude \(\pm F_0\), for which \(b_k = 4F_0/(k\pi)\) for odd \(k\). Verify that the series sums exactly to \(F_0^2\), then compute the fraction of the mean square captured by harmonics up to \(k = 1, 3, 5, 7\) and find how many non-zero terms are needed for \(99\%\) and for \(99.9\%\).
- Repeat for a triangular wave of the same peak value, for which \(a_k = 8F_0/(\pi^2k^2)\) for odd \(k\) and \(\overline{F^2} = F_0^2/3\). Explain the very different convergence rate in terms of the smoothness of the two waveforms, and say which is the better model of a real wave force.
- Now apply Parseval to the response of the barge of Problem 1. Compute the share of the mean-square surge carried by each harmonic and the number of harmonics needed for \(99\%\) of it. Compare with your answer to (b).
- Repeat (d) for a stiff bottom-founded structure excited by the same square-wave force but with \(\omega_n = 15\,\omega_0\). State the practical rule for choosing the number of harmonics to retain.
Problem 4 turns on a single idea: the same wave reaches different parts of a structure at different times, and a delay in time is a phase shift in frequency. Figure 3.9 shows the two arrangements the problem treats. Read it before starting, because the geometry is the whole difficulty — the algebra afterwards is just the shift property.
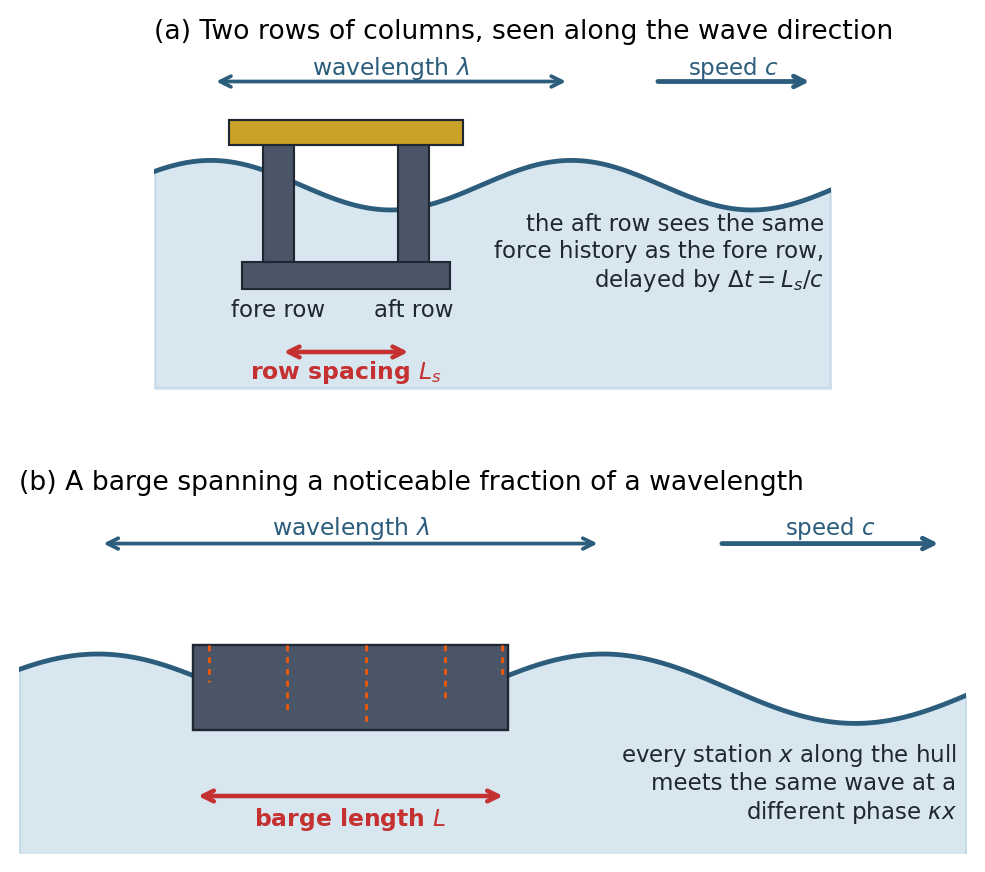
Column spacing, barge length and the cancellation period. Two consequences of the shift property, both of them used in real hull-form design. Throughout, use the deep-water results \(\lambda = gT^2/2\pi\) for the wavelength, \(c = gT/2\pi\) for the crest speed and \(\kappa = 2\pi/\lambda = \omega^2/g\) for the wavenumber; these will be derived in a later chapter.
- Prove the shift property \(\mathcal{F}\left(f(t-t_0)\right) = e^{-i\omega t_0}\hat{f}(\omega)\) directly from the definition, and note that \(\left\lvert e^{-i\omega t_0}\right\rvert = 1\): a pure delay changes only phase.
- A semi-submersible has two rows of columns, a distance \(L_s = 60\) m apart along the wave direction. Each row carries the same vertical wave force history, the aft row delayed by the time the crest takes to travel between them, \(\Delta t = L_s/c\). Show that the total force satisfies \(\hat{F}_{tot}(\omega) = \hat{F}(\omega)\left(1 + e^{-i\omega\Delta t}\right)\) with \(\left\lvert 1 + e^{-i\omega\Delta t}\right\rvert = 2\left\lvert\cos(\kappa L_s/2)\right\rvert\), and hence that the total force vanishes when \(L_s = \lambda/2\). Tabulate the gain for wave periods \(6, 8, 10, 12, 14\) and \(16\) s and find the cancellation period.
- The site has a peak wave period of \(10\) s. What row spacing places the cancellation there? Comment on why a designer cannot simply choose the spacing on this basis alone.
- In reality the aft row is partly shielded and receives only \(0.85\) of the force of the fore row. Recompute the gain at the cancellation period. How good is the cancellation now?
- A rectangular barge of length \(L = 100\) m, beam \(B = 24\) m and draft \(5\) m floats freely in head seas. The vertical wave force per unit length is \(f(x,t) = f_0\cos(\kappa x - \omega t)\) with \(f_0 = 55\) kN/m, taken independent of frequency for this exercise, and \(x\) measured from midships. Show that the total heave force is \(F(t) = f_0 L\,\mathrm{sinc}(\kappa L/2)\cos(\omega t)\), and identify this result with entry 16 of Table 3.1 with \((t,\omega)\) replaced by \((x,\kappa)\). Compute the barge’s heave natural period and \(\zeta = 0.20\) response amplitude at wave periods from \(5.66\) s to \(16\) s, and explain the two zeros you find.
Reading a decay test in the frequency domain. A spar platform is displaced in heave and released, and the decay is recorded. The measured record is well fitted by \(x(t) = X_0e^{-\zeta\omega_nt}\cos(\omega_dt)\) for \(t \geq 0\) with \(X_0 = 1.80\) m. The first positive peak is \(1.80\) m, the sixth is \(0.60\) m, and the two are \(140.1\) s apart. The amplitude spectrum \(\lvert\hat{x}(\omega)\rvert\) computed from the same record peaks at \(\omega = 0.2243\) rad/s and falls to \(1/\sqrt{2}\) of its peak value at \(\omega = 0.2164\) and \(0.2321\) rad/s.
- Using entry 14 of Table 3.1, write \(\hat{x}(\omega)\). Show that near the peak \(\lvert\hat{x}(\omega)\rvert \approx \dfrac{X_0/2}{\sqrt{(\omega_d-\omega)^2 + (\zeta\omega_n)^2}}\), and hence that the two half-power points are separated by \(\Delta\omega = 2\zeta\omega_n\). This is the half-power bandwidth method of extracting damping.
- Determine \(\zeta\), \(\omega_n\) and \(T_n\) from the spectrum. Independently determine \(\zeta\), \(T_d\) and \(\omega_n\) from the time-domain peaks by logarithmic decrement, and compare.
- The record was sampled for \(600\) s. Compute the time for the decay envelope to fall to \(1\%\) of its initial value, the frequency spacing \(\Delta\omega = 2\pi/T_{rec}\) of the Fourier coefficients of a \(600\) s record, and the number of spectral points that fall inside the half-power band. How long a record would you need for five points across the band, and is simply recording for longer the right answer? Justify your reasoning physically.
- The same record also contains the mooring-controlled surge mode, which appears as \(0.50\,e^{-\zeta_2\omega_2t}\cos(\omega_2t)\) with \(\omega_2 = 0.090\) rad/s and \(\zeta_2 = 0.10\). Compute the contribution of this second mode to \(\lvert\hat{x}\rvert\) at the heave peak frequency, as a percentage. Why is the frequency-domain estimate of damping more robust than the logarithmic decrement for a record containing two modes?
- Show that the product of the decay time to \(1\%\) and the half-power bandwidth is \(2\ln 100 = 9.21\), independent of \(\zeta\) and \(\omega_n\). Evaluate both quantities for this spar, for the same spar fitted with heave plates (\(\zeta = 0.15\)) and for a jacket sway mode (\(T_n = 4\) s, \(\zeta = 0.03\)), and state the principle in words.
A squall on a moored FPSO. A moored FPSO has an effective surge mass of \(2.8\times10^{8}\) kg, a total mooring stiffness of \(1.2\times10^{6}\) N/m and \(\zeta = 0.08\). It is initially at rest at its equilibrium position when a squall raises the wind force from zero to \(F_0 = 3.0\) MN, effectively instantaneously. The most heavily loaded mooring line carries a pretension of \(2.0\) MN and its tension rises by \(0.75\) MN for every metre of surge offset; the maximum allowable tension is \(5.0\) MN.
- Using the convolution integral \(\eqref{eq-convolution-irf}\) with the impulse response function derived in this chapter, show that the response to a step force applied at \(t=0\) is \[x(t) = \frac{F_0}{k}\left[1 - e^{-\zeta\omega_nt}\left(\cos\omega_dt + \frac{\zeta\omega_n}{\omega_d}\sin\omega_dt\right)\right]\]
- Compute \(\omega_n\), \(T_n\) and the static offset. Show that the maximum occurs at \(t = \pi/\omega_d\) with a dynamic amplification factor \(\mathrm{DAF} = 1 + e^{-\pi\zeta/\sqrt{1-\zeta^2}}\), evaluate it, and check the mooring line tension against its allowable value both statically and dynamically.
- The squall in fact lasts a finite time \(t_d\) before the wind drops again. Explain how superposition gives the response as the difference of two step responses, and compute the DAF for \(t_d/T_n = 0.1, 0.25, 0.5, 1.0\) and \(2.0\). Compare with the undamped result \(\mathrm{DAF} = 2\sin(\pi t_d/T_n)\) for \(t_d < T_n/2\), and explain why the DAF stops growing once \(t_d\) exceeds \(T_n/2\).
- Squalls at the site last several minutes. Which of your cases applies, and what is the worst credible offset?
- A real squall does not rise instantaneously. Take instead a force that ramps linearly from \(0\) to \(F_0\) over a time \(t_r\) and then stays constant, and compute the peak offset for \(t_r/T_n = 0.25, 0.5, 1.0\) and \(2.0\) by evaluating the convolution numerically. What property of the loading, rather than its magnitude, decides whether a structure responds dynamically?
Displacement, velocity and acceleration are three different spectra. The measured vertical motion of the bridge deck of a ship is analysed over a record and found to consist of the following harmonic components. The first four are wave-frequency motions; the fifth is the hull-girder whipping component of Problem 2.
component 1 2 3 4 5 \(\omega_j\) (rad/s) 0.35 0.52 0.70 0.95 6.912 \(X_j\) (m) 1.20 0.60 0.30 0.18 0.020 Crane operations must be suspended if the RMS vertical acceleration exceeds \(0.05g\).
- Using the derivative property of the Fourier transform, show that if \(x\) has a component of amplitude \(X_j\) at frequency \(\omega_j\) then \(\dot{x}\) and \(\ddot{x}\) have components of amplitude \(\omega_jX_j\) and \(\omega_j^2X_j\) at the same frequency, and state the corresponding relation between the complex Fourier coefficients \(c_k\) of a periodic signal and those of its derivatives.
- Tabulate the displacement, velocity and acceleration amplitude of each component. Which component is largest in each of the three quantities?
- Using Parseval’s theorem from Problem 3, compute the RMS displacement, velocity and acceleration. Must crane operations be suspended?
- Compute the share of the displacement variance and of the acceleration variance carried by the whipping component. Comment on the size of the two numbers.
- By what factor must the whipping amplitude be reduced for the criterion to be met? Compare with the effect of halving the largest wave-frequency component instead. What does this imply about a motion sensor, or a numerical model, that resolves only the wave frequency band?
The memory of the convolution. The convolution \(\eqref{eq-convolution-irf}\) says that the response now depends on the entire past of the force. This problem asks how much of that past actually matters, and what it costs.
- Verify from \(h(t) = \dfrac{\omega_n}{\sqrt{1-\zeta^2}}e^{-\zeta\omega_nt}\sin(\omega_dt)\) that \(h(0) = 0\), \(\dot{h}(0) = \omega_n^2\) and \(\displaystyle\int_0^{\infty}h(t)\,dt = 1\). Interpret the last result physically by comparing it with \(H(0)\).
- Define the memory time \(t_m\) as the time for the envelope of \(h\) to fall to \(1\%\) of its initial value. Show that \(t_m = \ln(100)/(\zeta\omega_n)\) and that the corresponding number of cycles is \(\ln(100)/(2\pi\zeta)\), independent of \(\omega_n\). Evaluate \(t_m\) in seconds and in cycles for: FPSO surge (\(T_n = 96\) s, \(\zeta = 0.08\)); bare spar heave (\(T_n = 28\) s, \(\zeta = 0.035\)); the same spar with heave plates (\(\zeta = 0.15\)); jacket sway (\(T_n = 4\) s, \(\zeta = 0.03\)).
- A three-hour simulation is run with a time step of \(0.1\) s. For each of the four modes, estimate the number of multiply–add operations needed to evaluate the convolution at every time step over the memory time, and compare with the \(5N\log_2N\) operations of an FFT-based frequency-domain solution of the whole record.
- Show that truncating the memory at \(t_m\) leaves an error bounded by \(\dfrac{F_{max}}{k}\dfrac{e^{-\zeta\omega_nt_m}}{\zeta\sqrt{1-\zeta^2}}\). For the bare spar with \(F_{max}/k = 0.5\) m, find the memory time needed to guarantee an error below \(1\) mm and compare it with the \(1\%\) envelope rule of part (b). Which is the safer criterion, and why do the two differ so much?
- Which mode is the most expensive to simulate in the time domain, and why is it also the one for which the frequency-domain approach is most attractive? Relate your answer to the number of cycles needed to build up a resonant response.
Two swells that are nearly the same. A moored structure is excited in heave by two swell systems arriving from nearly the same direction, giving a heave force \[F(t) = F_1\cos(\omega_1t) + F_2\cos(\omega_2t), \qquad F_1 = F_2 = 0.60~\text{MN}\] with \(\omega_1 = 0.480\) rad/s and \(\omega_2 = 0.520\) rad/s. The structure has an effective heave mass of \(4.2\times10^{7}\) kg, \(\omega_n = 0.50\) rad/s and \(\zeta = 0.02\).
- Show that \(F(t) = 2F_1\cos\left(\frac{\Delta\omega}{2}t\right)\cos\left(\bar{\omega}t\right)\) with \(\bar{\omega} = (\omega_1+\omega_2)/2\) and \(\Delta\omega = \omega_2-\omega_1\), and write down \(\hat{F}(\omega)\) using Table 3.1. Compute the group period, the carrier period and the number of waves per group.
- Compute the heave stiffness, and the amplitude and phase of each response component.
- Show that the response is also a beat, and compute the maximum and minimum of its envelope and the modulation depth \((\max-\min)/(\max+\min)\). Why is the minimum not zero, when the force envelope falls exactly to zero?
- Show that the response envelope peaks a time \(-\Delta\phi/\Delta\omega\) after the force envelope, where \(\Delta\phi = \phi_2-\phi_1\), and evaluate it. Verify numerically. Explain why the largest response does not occur when the largest wave group arrives.
- Recompute the number of waves per group for frequency separations \(\Delta\omega = 0.08, 0.04\) and \(0.02\) rad/s, and use the build-up result \(N_{95} = \ln(20)/(2\pi\zeta)\) from the previous chapter to find what fraction of the steady-state amplitude each group actually delivers. Which sea is the dangerous one, and what does this say about the steady-state answers computed in (b) and (c)?
Programming Problem: Three routes to the same answer. A slender compliant offshore tower has an effective mass of \(6.0\times10^{6}\) kg, a natural frequency \(\omega_n = 1.80\) rad/s and \(\zeta = 0.04\). In an oscillatory flow the horizontal force on a slender member is proportional to \(u\lvert u\rvert\), where \(u\) is the flow velocity — a result you will meet later, and which you should simply take as given here. With a wave of frequency \(\omega_0 = 0.60\) rad/s the horizontal force on the tower is therefore \[F(t) = F_0\cos(\omega_0t)\left\lvert\cos(\omega_0t)\right\rvert, \qquad F_0 = 1.2~\text{MN}\]
- Explain from the symmetries of \(F(t)\) why its Fourier series contains only odd cosine harmonics. Compute \(a_1, a_3, a_5, a_7\) numerically, by direct quadrature of the Fourier integrals and again with
numpy.fft.rfftapplied to one period, and compare \(a_1\) with the classical value \(8/(3\pi)\). Confirm that the even harmonics are zero to machine precision. - Compute the tower stiffness and \(\omega_n/\omega_0\). Tabulate the force amplitude, \(r_k\), \(\lvert H_k\rvert\) and the response amplitude of each harmonic up to \(k=6\), and report \(\sum_k\lvert x_k\rvert\) and \(\max\lvert x(t)\rvert\) obtained by summing the series.
- Solve the same problem in the time domain by evaluating the convolution \(\eqref{eq-convolution-irf}\) numerically with the impulse response function (
numpy.convolveis the natural tool). Run for \(140\) s, discard the first \(90\) s as transient and compare the steady-state maximum with (b). Repeat with \(\Delta t = 0.2, 0.1, 0.05, 0.02\) and \(0.01\) s and comment on the convergence. - Solve it a third time by integrating the equation of motion directly with a fourth-order Runge–Kutta scheme, and report the largest difference between the three solutions in the steady state.
- A common engineering shortcut replaces the drag force by an equivalent linear force retaining only the fundamental harmonic. What response does that shortcut predict, and by what factor is it in error? Explain precisely which piece of physics it discards.
- The ship moves to a site where the same tower sees waves of \(\omega_0 = 0.90\) rad/s, so that \(\omega_n = 2\omega_0\) exactly, the force amplitude being unchanged. Predict, before computing, whether the response will be larger or smaller, then compute \(\sum_k\lvert x_k\rvert\) and explain the result.
- Finally, repeat the FFT of part (a) over a window of \(4.0\) periods and then of \(4.3\) periods, and plot or list the resulting amplitude at each bin. Explain what you see in terms of the assumption that underlies every Fourier series.
- Explain from the symmetries of \(F(t)\) why its Fourier series contains only odd cosine harmonics. Compute \(a_1, a_3, a_5, a_7\) numerically, by direct quadrature of the Fourier integrals and again with
Answer Key
Problem 1 — A thruster that cannot make up its mind
(a) An on–off thrust is a mean value plus a square wave, and a square wave contains only odd harmonics.
Mean. \(a_0 = \frac{2}{T}\int_0^{T/2}F_0\,dt = F_0\), so the mean thrust is \(a_0/2 = F_0/2\).
Cosine terms. For \(k \ge 1\), \[a_k = \frac{2F_0}{T}\int_0^{T/2}\cos(k\omega_0t)\,dt = \frac{2F_0}{k\omega_0T}\sin(k\pi) = 0.\]
Sine terms. \[b_k = \frac{2F_0}{T}\int_0^{T/2}\sin(k\omega_0t)\,dt = \frac{F_0}{k\pi}\left[1 - (-1)^k\right],\] which is \(2F_0/(k\pi)\) for odd \(k\) and \(0\) for even \(k\).
Why the even harmonics vanish. \(F(t) - F_0/2\) is half-wave antisymmetric: \(F(t + T/2) - F_0/2 = -\left[F(t) - F_0/2\right]\). An even harmonic repeats itself after \(T/2\), so its product with such a function integrates to zero over a period.
(b) Each harmonic is treated as a separate regular force, through the RAO at its own frequency.
Stiffness and mean offset. \(\omega_n = 2\pi/20 = 0.31416\) rad/s, \(k = m\omega_n^2 = 2.3687 \times 10^{6}\) N/m and \(\omega_0 = 2\pi/60 = 0.10472\) rad/s, so \(\omega_n = 3\omega_0\) exactly. Mean offset \((F_0/2)/k = 0.1900\) m.
The harmonics.
\(k\) \(\omega_k\) (rad/s) \(F_k\) (kN) \(r_k\) \(\lvert H_k\rvert\) \(\phi_k\) (deg) \(\lvert x_k\rvert\) (m) 1 0.1047 573.0 0.3333 1.1242 -2.1 0.2719 3 0.3142 191.0 1.0000 10.0000 -90.0 0.8063 5 0.5236 114.6 1.6667 0.5600 -174.6 0.0271 7 0.7330 81.9 2.3333 0.2247 -177.0 0.0078 (c) The thruster never pushes at \(\omega_n\) on purpose, yet the barge responds almost entirely at \(\omega_n\), because the third harmonic of the thrust lands on resonance.
Dominant harmonic. The third carries only \(191\) kN, a third of the fundamental, but \(r_3 = 1\) and \(|H_3| = 1/(2\zeta) = 10\), so it produces \(0.806\) m against the fundamental’s \(0.272\) m.
Excursions. Summing the series, the surge ranges from \(-0.863\) m to \(1.243\) m: \(2.106\) m peak to peak about a mean offset of only \(0.190\) m.
Against the naive estimate. Mean thrust over stiffness understates the largest offset by a factor of \(6.5\) (figure below).

(d) Removing the resonant harmonic by reshaping the pulse helps little; moving the whole comb of harmonics away from \(\omega_n\) helps a lot.
General on-fraction. Over one period the thrust is \(F_0\) for \(0 < t < dT\), so \[c_k = \frac{F_0}{T}\int_0^{dT}e^{-ik\omega_0t}\,dt = \frac{F_0\left(1 - e^{-i2\pi kd}\right)}{i2\pi k},\] and the \(k\)-th real harmonic has amplitude \[2|c_k| = \frac{2F_0\lvert\sin(\pi kd)\rvert}{\pi k},\] which vanishes whenever \(kd\) is an integer. \(d = 1/2\) recovers part (a).
Proposal (i) (\(d = 1/3\), \(F_0 = 1350\) kN). The third harmonic is now exactly zero, but even harmonics appear: \(|x_1| = 0.3532\) m, \(|x_2| = 0.2808\) m, \(|x_3| = 0\), \(|x_4| = 0.0995\) m, so \(\sum_k|x_k| = 0.7931\) m against \(1.1131\) m originally: only \(29\%\) better. The amplitude had to rise by \(50\%\) to hold the mean, and the second harmonic at \(r_2 = 2/3\) is still amplified (\(|H| = 1.79\)).
Proposal (ii) (\(T = 45\) s). Now \(\omega_0 = 0.13963\) rad/s and the odd harmonics sit at \(r = 0.444, 1.333, 2.222,\ldots\), none near resonance. \(|x_1| = 0.3010\) m, \(|x_3| = 0.1022\) m, \(|x_5| = 0.0123\) m and \(\sum_k|x_k| = 0.4240\) m: \(2.6\) times smaller.
Recommendation: proposal (ii).

(e) Killing one harmonic is not the same as killing the response.
Why. The Fourier coefficients of a periodic signal are tied together by its shape and its mean. Forcing one of them to zero while holding the mean fixed pushes energy into its neighbours, which may be amplified almost as strongly.
The robust fix. Move the whole comb of harmonics \(k\omega_0\) so that none of them lands near \(\omega_n\): change the repetition period, not the pulse shape.
Problem 2 — Bow slamming and the whipping of a hull girder
(a) A short blow is broadband: its harmonics all have about the same size, set by the impulse, up to a frequency of order \(1/\tau\).
Small on-fraction. From Problem 1(d), \(2|c_k| = 2F_0|\sin(\pi kd)|/(\pi k)\). With \(\pi kd = \pi k\tau/T_e \ll 1\), \(\sin u \approx u\) gives \[2|c_k| \approx \frac{2F_0\tau}{T_e} = 0.8000\ \text{MN},\] the same for every \(k\). The height of this flat spectrum is set by the impulse \(F_0\tau = 3.0\) MN·s, not by the peak force alone.
First zero of the envelope. At \(\pi kd = \pi\), i.e. \(\omega = 2\pi/\tau = 31.42\) rad/s (\(f = 5.0\) Hz), which is harmonic \(k = T_e/\tau = 37.5\). About \(9\) harmonics lie within \(10\%\) of the flat value.
Why a short blow is broadband. The shorter the blow, the further out the first zero of its spectrum: a \(0.2\) s slam reaches frequencies ten times the wave frequency, where the hull girder lives.
(b) The eighth harmonic of the slams carries the same force as the first, but it sits near the girder’s resonance.
Mode. \(\omega_n = 2\pi(1.10) = 6.9115\) rad/s, \(k_m = M\omega_n^2 = 5.7323 \times 10^{8}\) N/m, \(\omega_0 = 0.8378\) rad/s and \(\omega_n/\omega_0 = 8.250\): harmonics \(8\) and \(9\) straddle the natural frequency. The mean force \(F_0d = 0.40\) MN gives a static offset of only \(0.70\) mm.
Harmonics.
\(k\) \(\omega_k\) (rad/s) \(F_k\) (MN) \(r_k\) \(\lvert H_k\rvert\) \(\lvert x_k\rvert\) (mm) 1 0.8378 0.7991 0.1212 1.015 1.41 2 1.6755 0.7963 0.2424 1.062 1.48 8 6.7021 0.7414 0.9697 15.609 20.19 9 7.5398 0.7263 1.0909 5.212 6.60 10 8.3776 0.7097 1.2121 2.127 2.63 Comparison. The wave-frequency component deflects the hull by \(1.41\) mm; the eighth harmonic, with a force of the same size, by \(20.19\) mm, \(14\) times more, because \(|H|\) is \(15.6\) there instead of \(1.01\). This is whipping: a ringing of the hull girder at about \(1\) Hz on top of the slow wave-frequency bending.

(c) The components that dominate the sum do not peak together, so the sum of amplitudes overestimates the peak.
Numbers. \(\sum_k|x_k| = 52.0\) mm, but the record runs from \(-24.9\) mm to \(33.0\) mm, only \(63\%\) of the bound.
Why the bound is loose. The harmonics that dominate the sum are near resonance and phase-shifted by about \(-90^\circ\) relative to the rest, so they never all peak at the same instant (figure below).

(d) A slam cannot be detuned: its spectrum is flat over the whole range in which the hull girder modes live.
Longer slam. With \(\tau = 0.4\) s the eighth harmonic grows to \(1.1621\) MN and the response to \(31.6\) mm, \(1.57\) times worse: the impulse \(F_0\tau\) has doubled while \(\omega_n\) is still far below the first envelope zero (\(15.7\) rad/s).
Placing a zero on the eighth harmonic. It needs \(8\tau/T_e = 1\), i.e. \(\tau = T_e/8 = 0.938\) s: a slam lasting almost a second, which is not a slam at all.
(e) Changing speed only reshuffles which harmonic falls nearest \(\omega_n\); the only reliable remedy is to stop the slamming.
Largest single-harmonic response.
\(T_e\) (s) worst \(k\) \(\omega_k\) (rad/s) \(\lvert H_k\rvert\) \(\lvert x_k\rvert\) (mm) 6.0 7 7.3304 7.85 12.5 7.0 8 7.1808 12.01 16.5 7.5 8 6.7021 15.61 20.2 8.0 9 7.0686 19.19 23.1 9.0 10 6.9813 31.62 33.9 Exact resonance. \(k\omega_0 = \omega_n\) needs \(T_e = 2\pi k/\omega_n = 7.273\) s (\(k = 8\)) or \(8.182\) s (\(k = 9\)). There \(|H| = 1/(2\zeta) = 41.7\) and the deflection reaches \(55\) mm, three times the value at \(T_e = 7.5\) s.
Remedy. The excitation cannot be detuned (part (d)), and \(|H|_{\max} = 1/(2\zeta)\) is fixed by a damping ratio of only \(1.2\%\). Reduce speed or change heading so that the bow stops emerging, or ballast to deepen the forefoot (figure below).

Problem 3 — How many harmonics do you actually need?
(a) Mean squares of harmonics add, because every cross term integrates to zero.
Expansion. Substitute the series for \(F(t)\) into \(\frac{1}{T}\int F^2\,dt\). Products of two different basis functions integrate to zero by orthogonality, so only the squares survive: \[\frac{1}{T}\int\left(\frac{a_0}{2}\right)^2dt = \frac{a_0^2}{4}, \qquad \frac{1}{T}\int a_k^2\cos^2(k\omega_0t)\,dt = \frac{a_k^2}{2},\] and likewise \(b_k^2/2\).
Complex form. \(|c_k|^2 = (a_k^2 + b_k^2)/4\), and \(k\) and \(-k\) both contribute.
Takeaway. Mean squares add; amplitudes do not.
(b) A square wave converges slowly: its harmonics fall off only as \(1/k\).
Check. \[\frac{1}{2}\sum_{k\,\text{odd}}\left(\frac{4F_0}{k\pi}\right)^2 = \frac{8F_0^2}{\pi^2}\sum_{k\,\text{odd}}\frac{1}{k^2} = \frac{8F_0^2}{\pi^2}\cdot\frac{\pi^2}{8} = F_0^2,\] the mean square of a \(\pm F_0\) square wave.
Cumulative fractions. \(k \le 1\): \(81.06\%\); \(k \le 3\): \(90.06\%\); \(k \le 5\): \(93.31\%\); \(k \le 7\): \(94.96\%\).
Terms needed. \(99\%\) needs \(k = 41\) (21 terms) and \(99.9\%\) needs \(k = 405\) (203 terms). The tail behaves like \(\sum_{k>K}1/k^2 \sim 1/(2K)\), so the error falls only as \(1/K\).
(c) Each extra degree of smoothness buys one more power of \(k\) in the decay of the coefficients.
Triangular wave. \(k \le 1\): \(98.553\%\); \(k \le 3\): \(99.770\%\); \(k \le 5\): \(99.928\%\). Two terms already beat 21 terms of the square wave.
Why. The square wave is discontinuous: coefficients \(\propto 1/k\), energy \(\propto 1/k^2\). The triangular wave is continuous with a discontinuous slope: coefficients \(\propto 1/k^2\), energy \(\propto 1/k^4\).
Real wave forces are smooth, so a handful of harmonics normally suffices. The exception is impulsive loading like the slams of Problem 2, whose spectrum does not decay at all over the range of interest.
(d) The RAO weights each harmonic by \(|H_k|^2\) inside the Parseval sum, which collapses the tail of the response.
Shares of the mean-square surge. \(k = 1\): \(10.20\%\); \(k = 3\): \(89.69\%\); \(k = 5\): \(0.101\%\); \(k = 7\): \(0.008\%\).
Against (b). Two terms give \(99.89\%\) of the response mean square, against \(90.1\%\) for the same two terms of the force. Beyond resonance \(|H_k|^2\) falls as \(1/k^4\), on top of the force’s \(1/k^2\).
(e) The number of harmonics to keep is set by the structure, not by the force.
Stiff structure. With \(\omega_n = 15\omega_0\) the resonant harmonic is \(k = 15\), carrying \(23.9\%\) of the response mean square (the quasi-static fundamental \(54.3\%\)); \(99\%\) now needs harmonics up to \(k = 17\).
Rule. Keep every harmonic up to at least two or three times \(\omega_n/\omega_0\), however well converged the force series looks. Truncating where the force is well represented is one of the commonest ways to lose a resonance (figure below).

Problem 4 — Column spacing, barge length and the cancellation period
(a) A delay rotates the phase of every frequency component and changes no amplitude.
Proof. With \(\xi = t - t_0\), \[\begin{aligned} \mathcal{F}\left(f(t - t_0)\right) &= \int_{-\infty}^{\infty}f(t - t_0)e^{-i\omega t}\,dt \\ &= \int_{-\infty}^{\infty}f(\xi)e^{-i\omega(\xi + t_0)}\,d\xi \\ &= e^{-i\omega t_0}\hat f(\omega). \end{aligned}\]
Meaning. \(|e^{-i\omega t_0}| = 1\), so only the phase changes, by \(\omega t_0\). That is exactly why two delayed copies of the same force can cancel.
(b) Two rows half a wavelength apart see opposite forces, so their sum cancels.
Total force. \(F_{\text{tot}}(t) = f(t) + f(t - \Delta t)\), so by linearity and (a) \[\hat F_{\text{tot}} = \hat F\left(1 + e^{-i\omega\Delta t}\right) = \hat F\,2e^{-i\omega\Delta t/2}\cos(\omega\Delta t/2).\]
Gain. \(\omega\Delta t = \omega L_s/c = L_s\omega^2/g = \kappa L_s\), so the gain is \(2|\cos(\kappa L_s/2)|\). It vanishes at \(\kappa L_s/2 = \pi/2\), i.e. \(L_s = \lambda/2\): one row under a crest while the other is under a trough.
Table.
\(T\) (s) \(\lambda\) (m) \(\Delta t\) (s) gain \(2\lvert\cos(\kappa L_s/2)\rvert\) 6 56.2 6.40 1.9552 8 99.9 4.80 0.6208 10 156.1 3.84 0.7111 12 224.8 3.20 1.3373 14 306.0 2.74 1.6324 16 399.7 2.40 1.7817 Cancellation period. \(\lambda = 2L_s = 120\) m, i.e. \(T = \sqrt{4\pi L_s/g} = 8.77\) s. Long waves approach a gain of \(2\): the platform sees them as one rigid body.
(c) The cancellation is narrow, and the spacing is fixed by many other requirements.
Spacing for \(10\) s. \(L_s = gT^2/(4\pi) = 78.1\) m.
Why not choose it on this basis alone. The notch only helps if the sea really is concentrated at \(10\) s. The spacing also sets the deck area, the transverse stability (waterplane inertia grows with the spacing squared) and the pontoon structure, and the same spacing produces a reinforcement peak in pitch.
(d) Unequal contributions leave a residual: cancellations in real hulls are deep but never perfect.
Gain. \(\left|1 + \alpha e^{-i\kappa L_s}\right|\) with \(\alpha = 0.85\) has a minimum of \(1 - \alpha = 0.15\) instead of \(0\); at \(T = 8.77\) s it is \(0.1500\).
How good. Against the long-wave gain of \(1 + \alpha = 1.85\) this is still a \(92\%\) reduction.

(e) The wave force on a hull is the spatial Fourier transform of its length, evaluated at the wavenumber of the wave: a long hull is a poor collector of short waves.
Total force. With \(x\) from midships, \[\begin{aligned} F(t) &= \int_{-L/2}^{L/2}f_0\cos(\kappa x - \omega t)\,dx \\ &= f_0\cos(\omega t)\int_{-L/2}^{L/2}\cos(\kappa x)\,dx \\ &= f_0L\,\text{sinc}(\kappa L/2)\cos(\omega t), \end{aligned}\] the \(\sin(\kappa x)\) part vanishing by symmetry. This is entry 16 of Table 3.1 (the transform of a rectangle) with \((t, \omega)\) replaced by \((x, \kappa)\).
Heave. \(C_{33} = \rho gLB = 2.4133 \times 10^{7}\) N/m, \(m = \rho\nabla = 1.2300 \times 10^{7}\) kg, \(\omega_{n3} = \sqrt{g/T_{\text{draft}}} = 1.4007\) rad/s and \(T_{n3} = 4.49\) s.
\(T\) (s) \(\lambda\) (m) \(\mathrm{sinc}(\kappa L/2)\) \(\lvert F\rvert\) (MN) \(r\) \(\lvert H\rvert\) heave (m) 5.66 50.0 -0.0004 0.0019 0.793 2.0463 0.0002 6.00 56.2 -0.1144 0.6293 0.748 1.8766 0.0489 7.00 76.5 -0.2002 1.1009 0.641 1.5560 0.0710 8.00 99.9 -0.0008 0.0042 0.561 1.3863 0.0002 9.00 126.5 0.2460 1.3530 0.498 1.2860 0.0721 10.00 156.1 0.4494 2.4715 0.449 1.2215 0.1251 12.00 224.8 0.7049 3.8770 0.374 1.1453 0.1840 14.00 306.0 0.8334 4.5836 0.320 1.1032 0.2095 16.00 399.7 0.9002 4.9509 0.280 1.0774 0.2210 The two zeros. \(\kappa L/2 = n\pi\): the barge spans a whole number of wavelengths (\(\lambda = L = 100\) m at \(T = 8.00\) s, \(\lambda = L/2 = 50\) m at \(T = 5.66\) s), and the crests and troughs along it cancel exactly. The zeros come from the excitation, not from the RAO, which varies smoothly (figure below).

Problem 5 — Reading a decay test in the frequency domain
(a) A decaying oscillation transforms into a resonance curve whose half-power width is the decay rate.
Transform. Entry 14 with \(\alpha = \zeta\omega_n\) and \(\omega_0 = \omega_d\): \[\hat x(\omega) = X_0\frac{\alpha + i\omega}{(\alpha + i\omega)^2 + \omega_d^2}.\]
Near the peak. The denominator is \((\omega_d^2 - \omega^2 + \alpha^2) + i2\alpha\omega\). For \(\omega \approx \omega_d\), \(\omega_d^2 - \omega^2 \approx 2\omega_d(\omega_d - \omega)\) and \(\alpha^2\) is negligible, so the denominator is about \(2\omega_d\left[(\omega_d - \omega) + i\alpha\right]\) and the numerator about \(i\omega_dX_0\): \[|\hat x| \approx \frac{X_0/2}{\sqrt{(\omega_d - \omega)^2 + \alpha^2}}.\]
Half-power points. The peak is \(X_0/(2\alpha)\) at \(\omega_d\), and \(|\hat x|\) falls to \(1/\sqrt2\) of it where \((\omega_d - \omega)^2 = \alpha^2\), i.e. at \(\omega_d \pm \alpha\). So \(\Delta\omega = 2\alpha = 2\zeta\omega_n\).
(b) The spectrum and the time record give the same damping: a slow decay in time is a narrow peak in frequency.
From the spectrum. \(\zeta = (0.2321 - 0.2164)/(2\times0.2243) = 0.03500\), \(\omega_n \approx \omega_d/\sqrt{1 - \zeta^2} = 0.22444\) rad/s, \(T_n = 28.00\) s.
From the peaks. \(\delta = \tfrac15\ln(1.80/0.60) = 0.21972\), \(\zeta = \delta/\sqrt{4\pi^2 + \delta^2} = 0.03495\), \(T_d = 140.1/5 = 28.02\) s, \(\omega_d = 0.22424\) rad/s, \(\omega_n = 0.22438\) rad/s, \(T_n = 28.00\) s.
Agreement. Better than \(0.1\%\) in \(\zeta\).
(c) The record has died long before \(600\) s; zero-padding, not recording longer, gives the frequency resolution.
Decay time. \(\zeta\omega_n = 0.007842\) s\(^{-1}\), so the envelope reaches \(1\%\) after \(\ln(100)/(\zeta\omega_n) = 587\) s.
Resolution. \(\Delta\omega = 2\pi/600 = 0.01047\) rad/s against a half-power band of \(2\zeta\omega_n = 0.01568\) rad/s: only \(1.5\) points across the peak. Five points need \(T_{\text{rec}} \ge 5(2\pi)/(2\zeta\omega_n) = 2003\) s.
Record longer? No: after \(587\) s there is nothing left to record. Zero-pad the record to the required length instead. The transient has finite duration, so its continuous transform is fixed by the part already measured, and padding interpolates the true \(\hat x(\omega)\) rather than inventing information.
(d) The Fourier transform separates what the time record mixes.
Second mode at the heave peak (\(\omega = 0.2243\) rad/s). Heave contributes \(|\hat x_1| = 114.8\) m·s, surge \(|\hat x_2| = 2.65\) m·s: only \(2.3\%\).
Why the spectrum is more robust. The two modes are separate peaks in frequency, so the bandwidth at the heave peak belongs to heave alone. In time they are superposed: peaks no longer fall exactly \(T_d\) apart, successive peak ratios wander, and the logarithmic decrement returns a meaningless mix of the two dampings (figure below).

(e) Duration in time and width in frequency are reciprocal.
Product. \[t_{1\%}\,\Delta\omega = \frac{\ln 100}{\zeta\omega_n}\cdot2\zeta\omega_n = 2\ln 100 = 9.21,\] for every linear single degree of freedom system.
system \(T_n\) (s) \(\zeta\) \(t_{1\%}\) (s) \(\Delta\omega\) (rad/s) product spar heave (bare) 28.0 0.035 587 0.01568 9.21 spar heave (heave plates) 28.0 0.150 137 0.06731 9.21 jacket sway 4.0 0.030 98 0.09425 9.21 In words. A lightly damped mode rings for a long time and occupies a narrow band; a well damped one dies quickly and spreads over a wide band. A short record and a sharp spectral peak cannot be had together, which is why lightly damped tests need long runs.
Problem 6 — A squall on a moored FPSO
(a) The step response is the running integral of the impulse response.
Convolution. With \(F = F_0\) for \(\tau > 0\), \(x(t) = \frac{F_0}{k}\int_0^th(s)\,ds\), where \(h(s) = \frac{\omega_n}{\sqrt{1 - \zeta^2}}e^{-\zeta\omega_ns}\sin\omega_ds = \frac{\omega_n^2}{\omega_d}e^{-\zeta\omega_ns}\sin\omega_ds\).
Integral. With \(a = \zeta\omega_n\), \(b = \omega_d\) and \(a^2 + b^2 = \omega_n^2\), \[\int_0^te^{-as}\sin bs\,ds = \frac{b - e^{-at}(a\sin bt + b\cos bt)}{a^2 + b^2},\] which gives the result at once.
Check. The bracket is \(1\) at \(t = 0\) (so \(x(0) = 0\)) and decays to zero, leaving the static offset \(F_0/k\).
(b) A sudden load overshoots the static offset by almost a factor of two, and the mooring line fails the dynamic check although it passes the static one.
Mode. \(\omega_n = \sqrt{k/m} = 0.06547\) rad/s, \(T_n = 96.0\) s, static offset \(F_0/k = 2.50\) m.
Peak. \(x\) is stationary where \(\sin\omega_dt = 0\); the first maximum is at \(t = \pi/\omega_d = 48.1\) s, where \(\cos\omega_dt = -1\) and \[\mathrm{DAF} = 1 + e^{-\pi\zeta/\sqrt{1 - \zeta^2}} = 1.7771,\] a peak offset of \(4.443\) m.
Line tension. Static \(3.875\) MN, safe against \(5.0\) MN; dynamic \(5.332\) MN, \(7\%\) over the allowable.
(c) A finite squall is a step up followed by a step down; once it outlasts half a natural period, its length no longer matters.
Superposition. \(x(t) = x_{\text{step}}(t) - x_{\text{step}}(t - t_d)\).
\(t_d/T_n\) \(t_d\) (s) DAF (damped) \(2\sin(\pi t_d/T_n)\) peak offset (m) 0.10 9.6 0.5483 0.6180 1.371 0.25 24.0 1.2548 1.4142 3.137 0.50 48.0 1.7771 2.0000 4.443 1.00 96.0 1.7771 2.0000 4.443 2.00 192.0 1.7771 2.0000 4.443 Interpretation. A squall shorter than about a fifth of \(T_n\) does not even reach the static offset: there is no time to move. Once \(t_d > T_n/2\) the peak has already happened during the squall, at \(t = \pi/\omega_d\), so the DAF saturates at the step value; damping lowers the undamped ceiling of \(2\) to \(1.777\).
(d) Only the suddenness of the squall matters, not its duration.
Which case. \(T_n = 96\) s, so a squall of several minutes has \(t_d \gg T_n/2\): the saturated case. Peak offset \(4.44\) m, peak line tension \(5.33\) MN.
(e) The rise time of a load compared with the natural period, not its size, decides whether a problem is dynamic.
Ramp loading (numerical convolution of \(F\) with \(h\)):
\(t_r/T_n\) \(t_r\) (s) DAF peak offset (m) line tension (MN) 0.25 24.0 1.6997 4.249 5.187 0.50 48.0 1.4955 3.739 4.804 1.00 96.0 1.0553 2.638 3.979 2.00 192.0 1.0443 2.611 3.958 Interpretation. A squall that takes one natural period to build up gives almost no amplification, and the line stays within its allowable. The same principle covers a mooring line parting (rise time zero, DAF near \(2\) on the remaining lines) and a slow tidal or current build-up (DAF \(\to 1\)) (figure below).

Problem 7 — Displacement, velocity and acceleration are three different spectra
(a) Each differentiation multiplies a component by \(i\omega\): its amplitude by \(\omega\) and its phase by a quarter turn.
Transform. \(\mathcal{F}(\dot x) = i\omega\hat x(\omega)\) and \(\mathcal{F}(\ddot x) = (i\omega)^2\hat x = -\omega^2\hat x\).
Periodic signal. Term by term, \(x = \sum_kc_ke^{ik\omega_0t}\) gives coefficients \(ik\omega_0c_k\) for \(\dot x\) and \(-(k\omega_0)^2c_k\) for \(\ddot x\). A component of amplitude \(X_j\) at \(\omega_j\) therefore has amplitude \(\omega_jX_j\) in velocity and \(\omega_j^2X_j\) in acceleration.
(b) The ranking of the components changes every time we differentiate.
\(j\) \(\omega_j\) (rad/s) \(X_j\) (m) \(\omega_jX_j\) (m/s) \(\omega_j^2X_j\) (m/s\(^2\)) 1 0.350 1.200 0.4200 0.1470 2 0.520 0.600 0.3120 0.1622 3 0.700 0.300 0.2100 0.1470 4 0.950 0.180 0.1710 0.1624 5 6.912 0.020 0.1382 0.9555 Largest. Displacement and velocity: component \(1\). Acceleration: component \(5\). The whipping component is \(1.7\%\) of the largest displacement amplitude, yet its acceleration is \(5.9\) times the largest wave-frequency acceleration.
(c) Parseval gives each RMS value directly from the amplitudes.
RMS values. \(x_{\text{rms}} = \sqrt{\tfrac12\sum X_j^2} = 0.9805\) m, \(\dot x_{\text{rms}} = 0.4279\) m/s and \(\ddot x_{\text{rms}} = 0.7103\) m/s\(^2 = 0.0724g\).
Crane criterion. \(0.05g = 0.4905\) m/s\(^2\), exceeded by \(45\%\): crane operations must be suspended.
(d) A vibration invisible in the displacement record dominates the acceleration record.
Shares. The whipping component carries \(0.021\%\) of the displacement variance and \(90.5\%\) of the acceleration variance.
Without it. RMS displacement \(0.981 \to 0.980\) m, practically unchanged; RMS acceleration \(0.710 \to 0.219\) m/s\(^2 = 0.0223g\), comfortably inside the limit.
Why. The \(\omega^2\) weighting favours the whipping by \((6.912/0.35)^2 \approx 390\) (figure below).

(e) Sample fast enough, and filter last: a model that misses the whipping misses the acceleration.
Whipping allowed. At most \(0.6207\) m/s\(^2\), an amplitude of \(0.0130\) m: the \(20\) mm ring must come down to about \(13\) mm, a factor of \(1.54\).
Halving the largest wave component instead. RMS acceleration falls only to \(0.0718g\), still above the limit.
Consequence. A sensor, filter or code that resolves only the wave band would report \(0.0223g\) and declare the operation safe, while the crew experience \(0.0724g\).
Problem 8 — The memory of the convolution
(a) The area under the impulse response is the static response to a unit force, which is one.
Initial values. \(h(0) = 0\) because \(\sin 0 = 0\), and \(\dot h(0) = \frac{\omega_n}{\sqrt{1 - \zeta^2}}\,\omega_d = \omega_n^2\).
Area. \(\int_0^\infty e^{-\zeta\omega_nt}\sin\omega_dt\,dt = \omega_d/\omega_n^2\), so \[\int_0^\infty h\,dt = \frac{\omega_n}{\sqrt{1 - \zeta^2}}\cdot\frac{\omega_d}{\omega_n^2} = 1.\]
Meaning. This is \(\hat h(0) = H(0) = 1\): a force held constant forever produces the static deflection \(F_0/k\). It is the standard check on a numerically computed impulse response.
(b) Memory, like build-up, is counted in cycles, and the count depends on \(\zeta\) alone.
Memory time. The envelope \(\frac{\omega_n}{\sqrt{1 - \zeta^2}}e^{-\zeta\omega_nt}\) falls to \(1\%\) when \(e^{-\zeta\omega_nt_m} = 0.01\), so \(t_m = \ln(100)/(\zeta\omega_n)\), and dividing by \(T_n = 2\pi/\omega_n\) gives \(\ln(100)/(2\pi\zeta)\) cycles.
mode \(T_n\) (s) \(\zeta\) \(t_m\) (s) cycles samples at \(\Delta t = 0.1\) s FPSO surge 96 0.080 880 9.2 8795 spar heave (bare) 28 0.035 586 20.9 5863 spar heave (heave plates) 28 0.150 137 4.9 1368 jacket sway 4 0.030 98 24.4 977

(c) The convolution is one to two orders of magnitude more expensive than the frequency-domain solution.
Cost. The record has \(N = 3\times3600/0.1 = 108000\) steps, each costing \(t_m/\Delta t\) operations:
mode operations (convolution) operations (FFT) ratio FPSO surge \(9.50 \times 10^{8}\) \(9.03 \times 10^{6}\) 105 spar heave (bare) \(6.33 \times 10^{8}\) \(9.03 \times 10^{6}\) 70 spar heave (heave plates) \(1.48 \times 10^{8}\) \(9.03 \times 10^{6}\) 16 jacket sway \(1.06 \times 10^{8}\) \(9.03 \times 10^{6}\) 12 Conclusion. All four share the same \(N\); what differs is the memory. This is why linear seakeeping is done in the frequency domain and the convolution is reserved for genuinely nonlinear problems.
(d) A rigorous error bound needs a much longer memory than the \(1\%\) envelope rule, because it ignores the cancellation of the oscillating tail.
Bound. \[\begin{aligned} \left|\frac{1}{k}\int_{t_m}^{\infty}F(t - s)h(s)\,ds\right| &\le \frac{F_{\max}}{k}\int_{t_m}^{\infty}|h(s)|\,ds \\ &\le \frac{F_{\max}}{k}\frac{\omega_n}{\sqrt{1 - \zeta^2}}\int_{t_m}^{\infty}e^{-\zeta\omega_ns}\,ds \\ &= \frac{F_{\max}}{k}\frac{e^{-\zeta\omega_nt_m}}{\zeta\sqrt{1 - \zeta^2}}. \end{aligned}\]
Bare spar. Setting this to \(1\) mm with \(F_{\max}/k = 0.5\) m gives \(t_m = 1218\) s, against \(586\) s from the \(1\%\) rule: \(2.1\) times longer.
Which is safer, and why they differ. The bound is safer but deliberately pessimistic: it replaces \(\sin\omega_ds\) by \(1\), as if the force reinforced every half cycle of \(h\), whereas the true tail alternates in sign and largely cancels. The extra factor is essentially \(1/\zeta = 29\).
(e) A lightly damped structure remembers its past for a long time because it takes a long time to reach steady state.
Most expensive. The FPSO surge mode, with the longest memory in seconds (\(880\) s) and the same number of time steps.
Why the frequency domain suits it. Light damping and a long period make the convolution worst and the frequency domain best. They are also the conditions for a slow resonant build-up: \(\ln(100)/(2\pi\zeta)\) cycles of memory and \(\ln(20)/(2\pi\zeta)\) cycles of build-up are the same statement.
Problem 9 — Two swells that are nearly the same
(a) Two close frequencies make a wave group: a carrier inside a slowly varying envelope. Its spectrum is just two close lines.
Beat form. With \(\omega_{1,2} = \bar\omega \mp \Delta\omega/2\) and \(\cos A + \cos B = 2\cos\frac{A + B}{2}\cos\frac{A - B}{2}\), \[F = 2F_1\cos\left(\frac{\Delta\omega}{2}t\right)\cos(\bar\omega t),\] a carrier at \(\bar\omega = 0.500\) rad/s inside an envelope at \(\Delta\omega/2\).
Spectrum. From entry 5, \(\hat F(\omega) = \pi F_1\left[\delta(\omega \mp \omega_1) + \delta(\omega \mp \omega_2)\right]\): two pairs of spikes.
Periods. The envelope \(|\cos(\Delta\omega t/2)|\) repeats every \(2\pi/\Delta\omega = 157.1\) s, the carrier period is \(12.57\) s, so a group holds \(\bar\omega/\Delta\omega = 12.5\) waves.
(b) Both components lie within \(4\%\) of resonance and are amplified about tenfold.
Stiffness. \(k = m\omega_n^2 = 1.0500 \times 10^{7}\) N/m; static deflection \(F_1/k = 0.0571\) m.
Components. \[\begin{array}{c|c|c|c|c} & r & |H| & \phi & |x|\ \text{(m)} \\ \hline 1 & 0.960 & 11.455 & -26.1^\circ & 0.6546 \\ 2 & 1.040 & 10.918 & -153.0^\circ & 0.6239 \end{array}\]
(c) The structure distorts the group as well as amplifying it.
Envelope. Two cosines of slightly different frequency and unequal amplitude give an envelope between \(|x_1| + |x_2| = 1.2784\) m and \(\left||x_1| - |x_2|\right| = 0.0307\) m, a modulation depth of \(0.9531\).
Why the minimum is not zero. The RAO is not flat across the group: \(|H_1| \ne |H_2|\), so the two responses cannot cancel completely even in antiphase.
(d) The biggest response arrives after the biggest group has passed, because the phase of the RAO swings quickly through resonance.
Lag. The response components are in phase when \((\omega_2 - \omega_1)t + (\phi_2 - \phi_1) = 2n\pi\), i.e. at \(t = -\Delta\phi/\Delta\omega\) (modulo the group period), whereas the forces are in phase at \(t = 0\). Here \(\Delta\phi = -126.9^\circ = -2.2147\) rad, so the response group lags by \(55.4\) s, about \(4.4\) wave periods.
Numerical check. The largest \(|x|\) is \(1.2775\) m at \(t = 210.5\) s, \(53.4\) s after a force-group peak; the small difference arises because the response can only peak at a crest of the carrier.
Why. The phase of the RAO swings through \(-90^\circ\) across resonance: the component below \(\omega_n\) lags its force a little, the one above lags a lot, and they come into step later (figure below).

(e) The narrow-band swell is the dangerous one: only a group that lasts longer than the structure’s memory drives it to its steady-state amplitude.
\(\Delta\omega\) (rad/s) group period (s) waves per group \(N\) \(1 - e^{-2\pi\zeta N}\) 0.08 78.5 6.2 0.544 0.04 157.1 12.5 0.792 0.02 314.2 25.0 0.957 Build-up. Steady state needs \(N_{95} = \ln(20)/(2\pi\zeta) = 23.8\) cycles of coherent forcing. The widely separated pair (\(\Delta\omega = 0.08\)) holds phase for only \(6.2\) waves and delivers about half the steady amplitude; the close pair (\(\Delta\omega = 0.02\)) holds it for \(25\) waves and delivers \(96\%\).
Meaning for (b) and (c). Those steady-state amplitudes are an upper bound, approached only when the two frequencies are close enough.
Problem 10 — Three routes to the same answer
(a) Two symmetries leave only odd cosine harmonics, and the drag force is mostly fundamental with a noticeable third harmonic.
Symmetries. \(F(-t) = F(t)\): even, so every \(b_k = 0\). \(F(t + T/2) = \cos(\theta + \pi)|\cos(\theta + \pi)| = -F(t)\): half-wave antisymmetric, so every even harmonic vanishes (Problem 1(a)).
Quadrature. \(a_1 = 0.848826F_0\), \(a_3 = 0.169765F_0\), \(a_5 = -0.024252F_0\), \(a_7 = 0.008084F_0\).
FFT of \(256\) samples of one period. \(a_1 = 0.848826F_0\), \(a_3 = 0.169765F_0\), \(a_5 = -0.024252F_0\): identical, because for a smooth periodic function the trapezoidal rule over a whole period (which is what the DFT is) converges faster than any power of the step.
Checks. \(8/(3\pi) = 0.848826\); even harmonics \(|a_2| \approx 1.0e-17F_0\), zero to machine precision. The force is \(85\%\) fundamental but carries a \(20\%\) third harmonic at \(3\omega_0\).
(b) The third harmonic of the drag force sits exactly on the natural frequency and dominates the motion.
Stiffness. \(k = m\omega_n^2 = 1.9440 \times 10^{7}\) N/m and \(\omega_n/\omega_0 = 3.0\).
\(k\) \(\omega_k\) (rad/s) \(F_k\) (MN) \(r_k\) \(\lvert H_k\rvert\) \(\lvert x_k\rvert\) (mm) 1 0.60 1.01859 0.3333 1.1245 58.920 2 1.20 0.00000 0.6667 1.7918 0.000 3 1.80 0.20372 1.0000 12.5000 130.992 4 2.40 0.00000 1.3333 1.2738 0.000 5 3.00 0.02910 1.6667 0.5609 0.840 6 3.60 0.00000 2.0000 0.3329 0.000 Totals. \(\sum_k|x_k| = 190.9\) mm and, summing the series, \(\max|x(t)| = 182.6\) mm. The third harmonic alone gives \(131.0\) mm against the fundamental’s \(58.9\) mm, from \(20\%\) of the force.
(c) The convolution converges to the frequency-domain answer, provided the time step resolves the response period.
Convolution with the impulse response, transient discarded after \(90\) s:
\(\Delta t\) (s) \(\max\lvert x\rvert\) (mm) 0.20 181.9902 0.10 182.4323 0.05 182.5282 0.02 182.5565 0.01 182.5703 Convergence. From below, as \(O(\Delta t^2)\), settling at \(182.57\) mm against \(182.58\) mm from (b).
Time step. \(\Delta t\) must resolve \(T_n = 3.49\) s, not the wave period: the structure oscillates three times faster than the force.
(d) Three arrangements of the same linear equation must agree; the agreement checks the arithmetic, not the physics.
Runge–Kutta (\(\Delta t = 0.02\) s): \(\max|x| = 182.562\) mm.
Agreement. The three routes agree to \(0.007\) mm, about \(0.004\%\).
(e) Keeping only the fundamental throws away the harmonic that the structure responds to.
Shortcut. \(a_1\) alone gives \(58.9\) mm against the true \(182.6\) mm: an underestimate by a factor of 3.1.
What is discarded. The higher harmonics generated by the nonlinearity of \(u|u|\). Equivalent linearisation preserves the energy dissipated per cycle at the wave frequency and says nothing about \(3\omega_0\), which is where this structure lives. Nonlinear forces feed structural modes far outside the wave band: the mechanism behind the ringing of compliant towers and TLPs (figure below).

(f) Smaller: with \(\omega_n = 2\omega_0\) the resonant harmonic would be the second, and the force has no even harmonics to offer.
Prediction. By the symmetry of part (a), \(a_2 = 0\); the harmonics that exist land at \(r = 0.5, 1.5, 2.5, \ldots\), all away from resonance.
Numbers. \(\sum_k|x_k| = 78.5\) mm (\(|x_1| = 69.8\) mm, \(|x_2| = 0.0\) mm, \(|x_3| = 8.3\) mm) against \(190.9\) mm at the first site: \(2.4\) times smaller for the same structure in a shorter wave.
Lesson. The arithmetic relation between \(\omega_0\) and \(\omega_n\), together with the harmonics the force happens to contain, decides the answer.
(g) A window that does not hold a whole number of periods creates a jump at the join, and the jump spreads energy over every bin: spectral leakage.
\(4.0\) periods. The energy lands in five bins only: bin \(4\): \(0.8488\), bin \(12\): \(0.1698\), bin \(20\): \(0.0243\), bin \(28\): \(0.0081\), bin \(36\): \(0.0037\). These are bins \(4, 12, 20, \ldots\): the first, third and fifth harmonics, with the correct amplitudes.
\(4.3\) periods. bin \(4\): \(0.7201\), bin \(5\): \(0.3211\), bin \(13\): \(0.1732\), bin \(3\): \(0.1605\), bin \(6\): \(0.1373\), and non-zero values in every other bin.
Why. The signal has not changed; the window has. A Fourier series represents a function that repeats with the window length, and \(4.3\) periods repeated has a jump at the join, whose coefficients decay only as \(1/k\) (Problem 3(c)). Records are therefore analysed over whole periods where possible, and tapered by a window function where not (figure below).
